
4 : 1
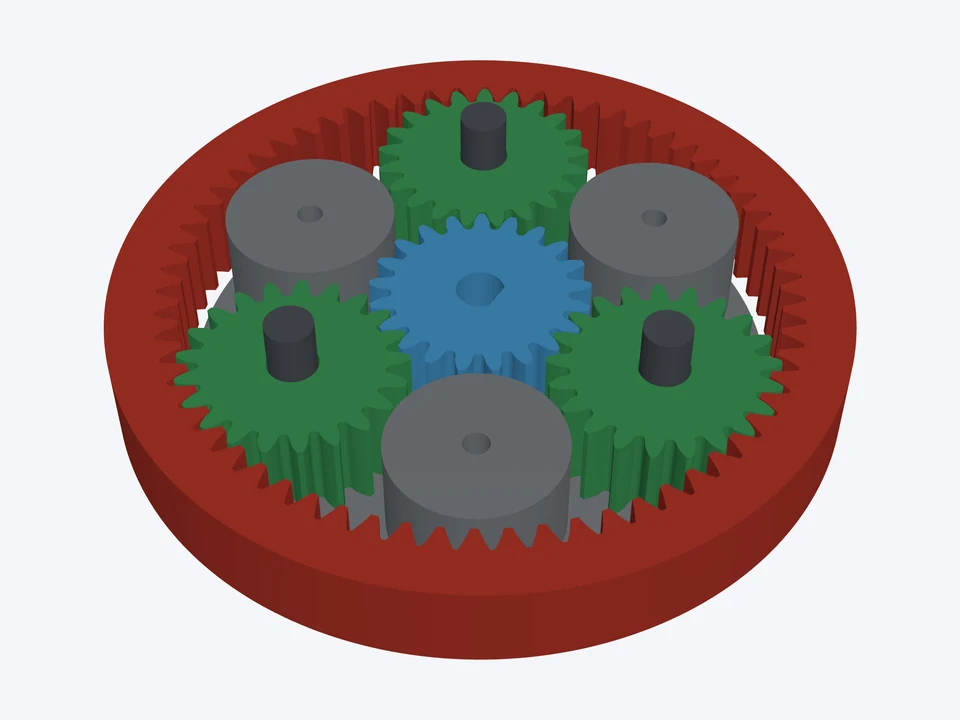

4 : 1 · NEMA 17 gearbox
Module 1 · 20° · spur
A one-stage 4 : 1 reducer for a NEMA 17 stepper: 5 mm D-flat sun, three planets, 8 mm output.
Stepper gearboxes, robot joints, FRC hex-shaft sets, desk toys and industrial reducers, one to three stages. Each opens in the Planetary Gear Designer with the sun, planets, ring and carrier assembled, in 3D, every setting in place and ready to change. Looking for something else? See the timing pulley, sprocket, gear, worm gear and bevel gear samples.
Module 1 · 20° · spur
A one-stage 4 : 1 reducer for a NEMA 17 stepper: 5 mm D-flat sun, three planets, 8 mm output.
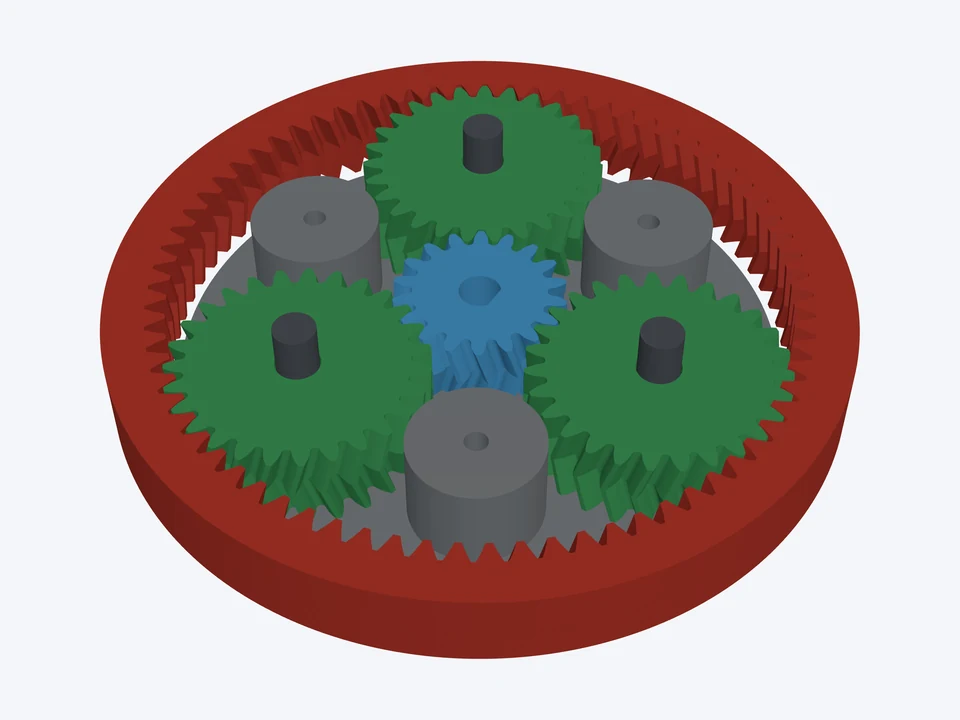

Module 1 · 20° · herringbone
5 : 1 in one stage; herringbone teeth run quietly and keep the planets in line.
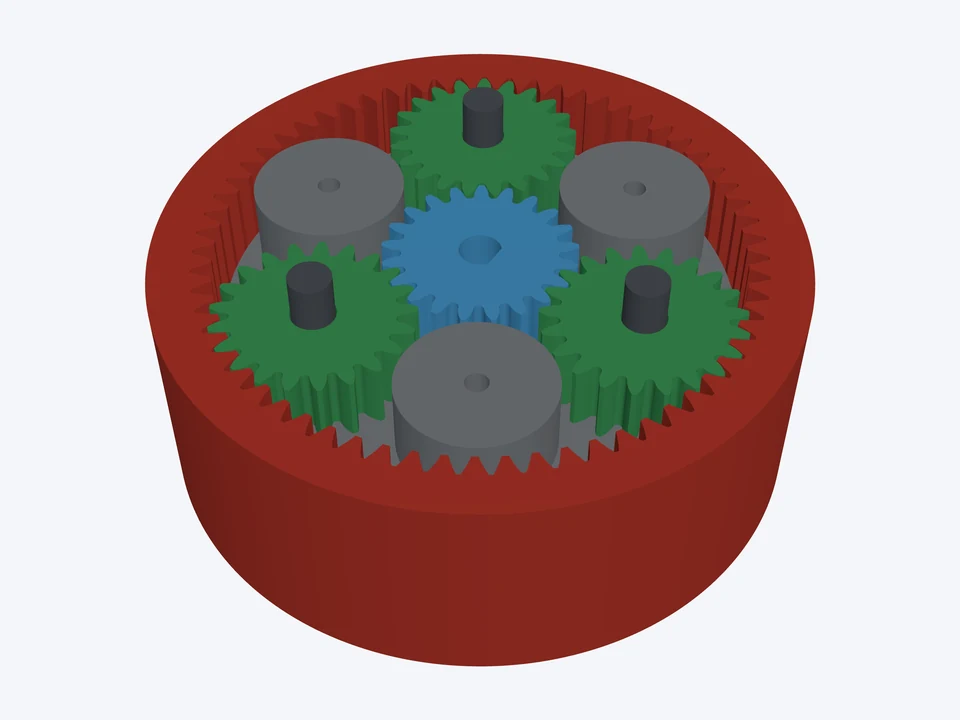

Module 1 · 20° · spur
Two stacked 4 : 1 stages: each carrier prints with the next stage's sun.
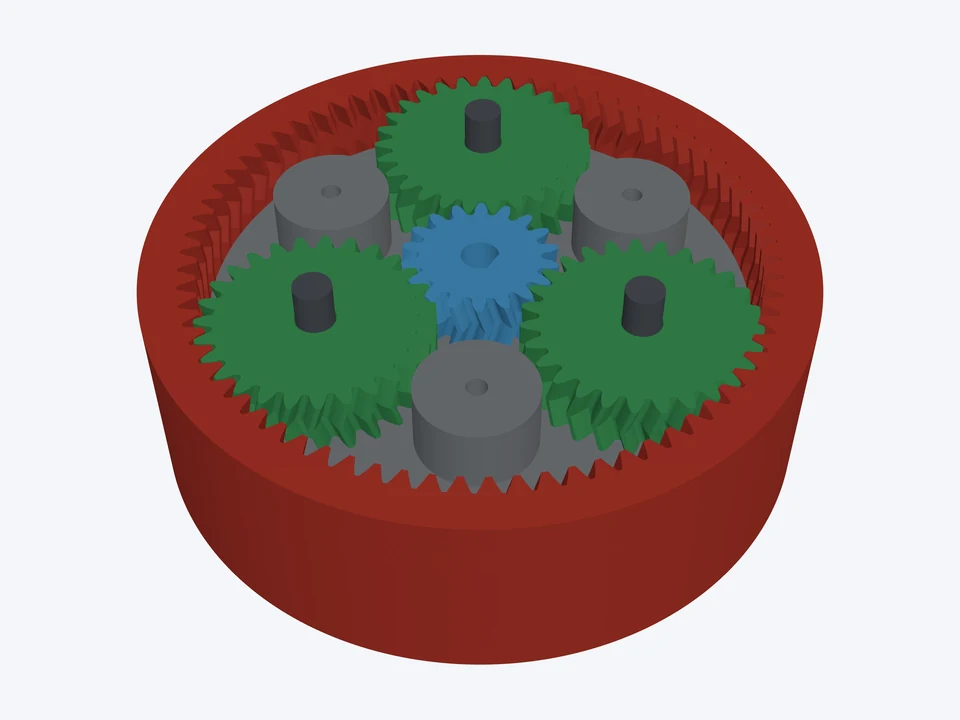

Module 1 · 20° · herringbone
Two 5 : 1 stages for slow, strong stepper output.
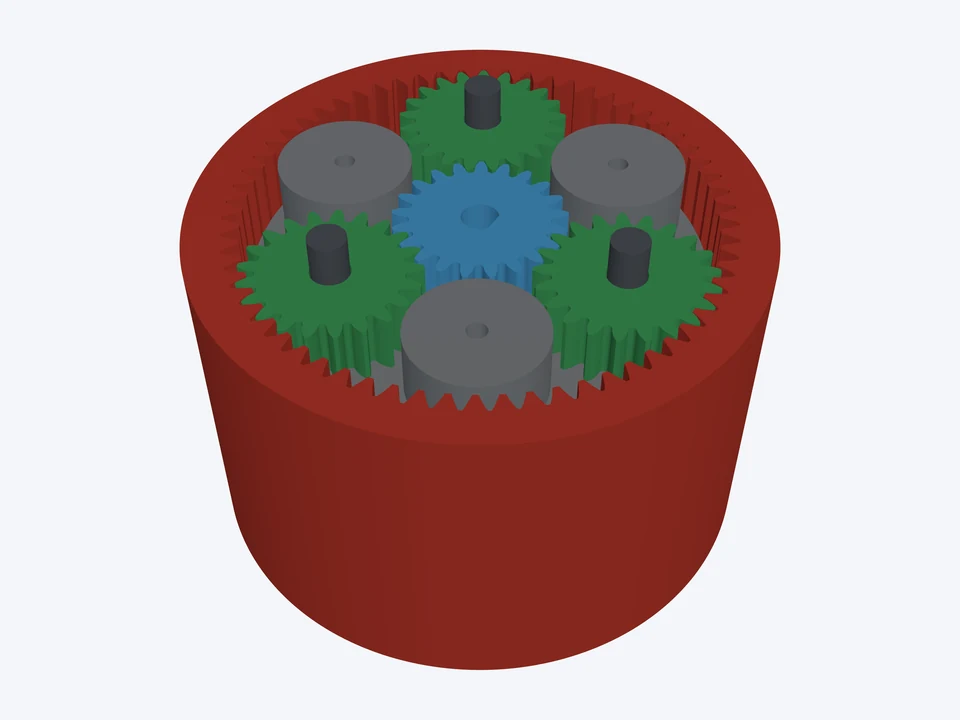

Module 1 · 20° · spur
Three 4 : 1 stages stacked: 64 : 1 for turntables, telescopes and slow axes.
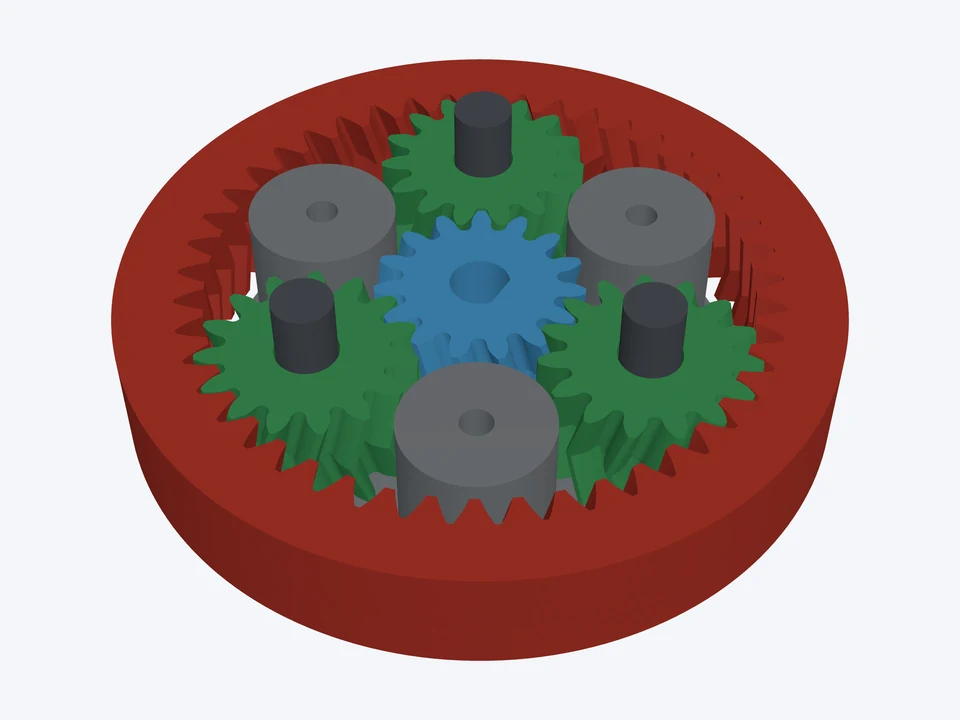

Module 1 · 20° · herringbone
A smaller 4 : 1: 15-tooth planets, shifted (x 0.2) so the ring's tips clear them; 60 mm across.
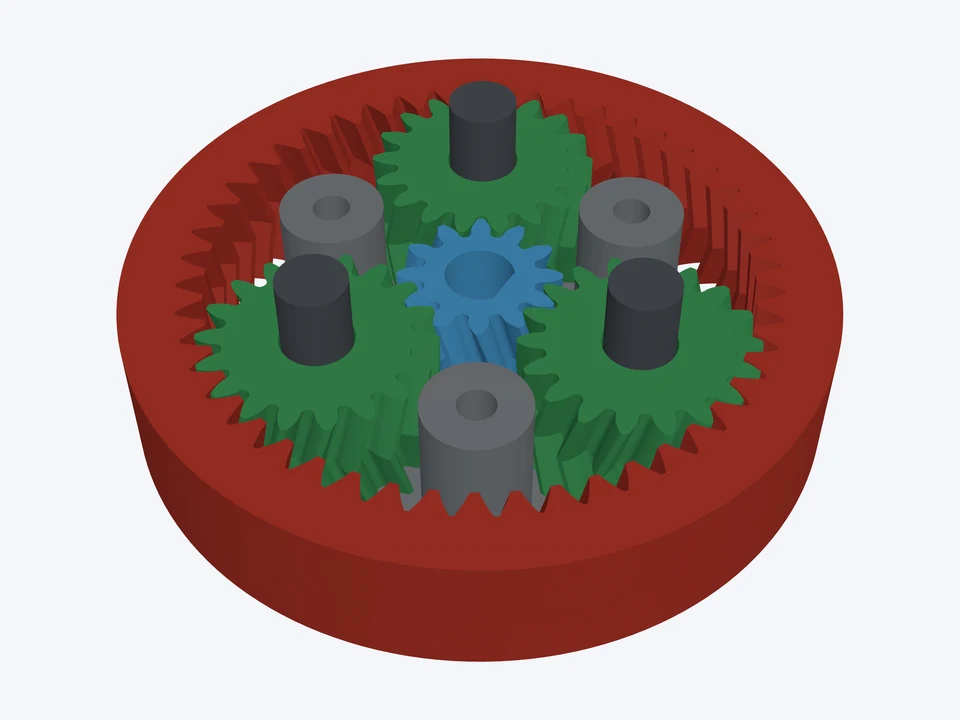

Module 0.8 · 20° · herringbone
5 : 1 at module 0.8 with a shifted 12-tooth sun and shifted planets: the smallest clean set, 51 mm across.


Module 1 · 20° · herringbone
Three compact 5 : 1 stages, 63 mm across, for solar trackers, telescope mounts and slow turntables.
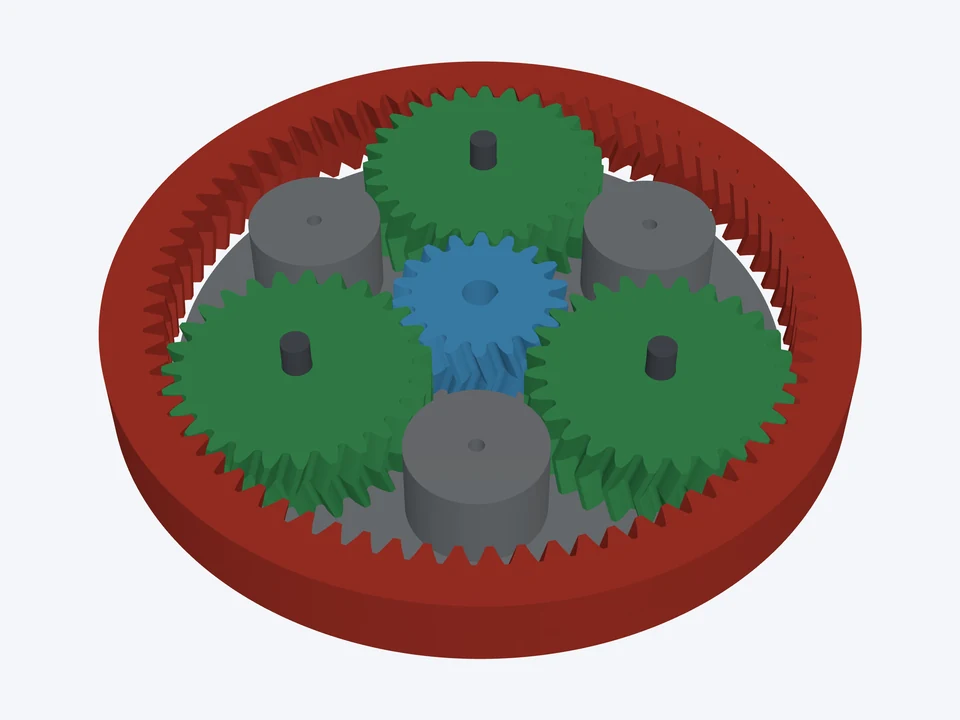

Module 1.5 · 20° · herringbone
A module 1.5 stage for a NEMA 23 on a ¼" D-flat shaft.
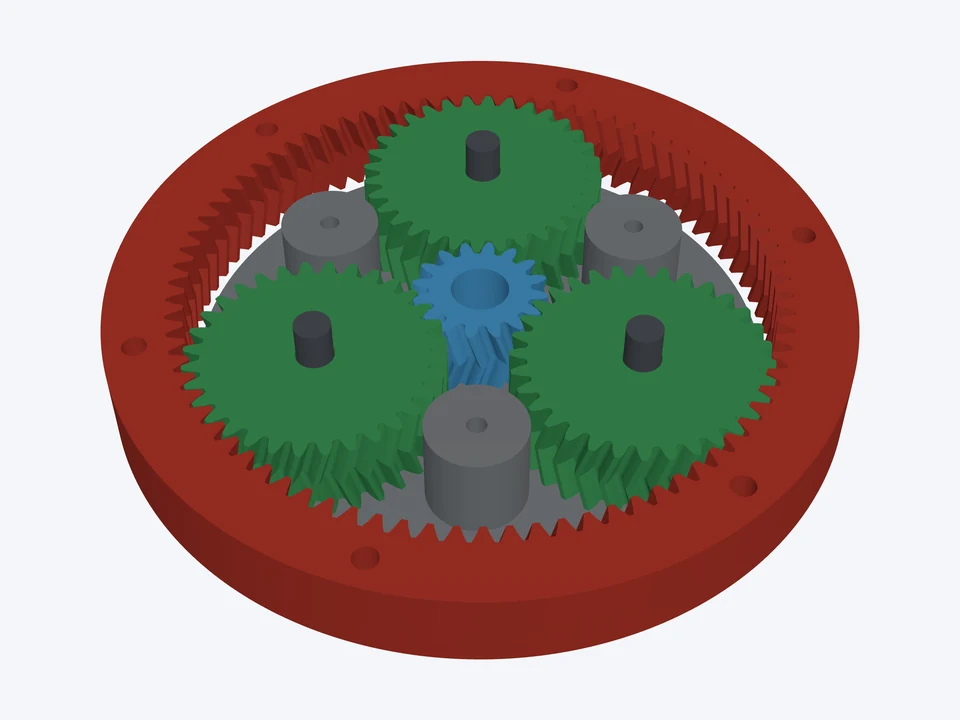

Module 1 · 20° · herringbone
The low-ratio stage legged robots put behind a brushless motor; flanged ring, six M3 bolts.
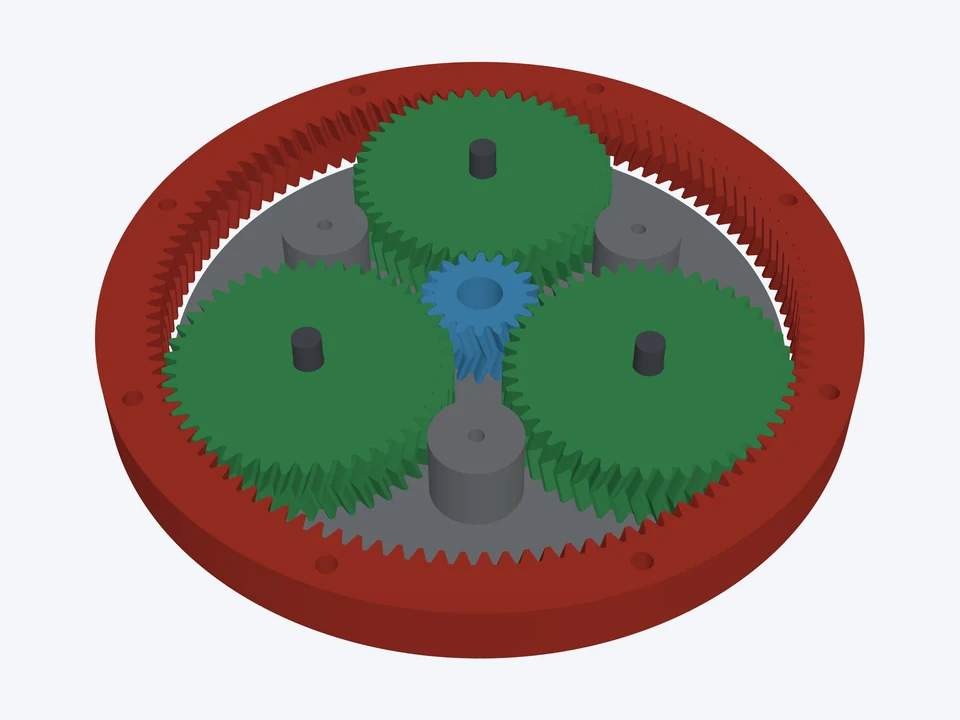

Module 1 · 20° · herringbone
7 : 1 in one stage: a small sun and big planets, still back-drivable.
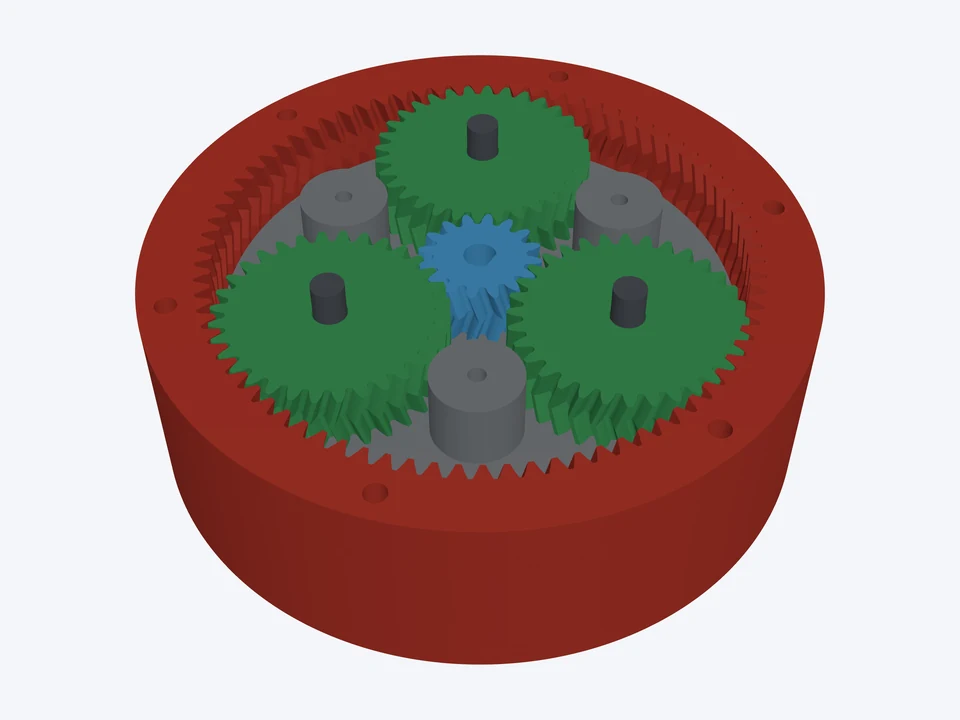

Module 1 · 20° · herringbone
Two 6 : 1 stages for a printed robot arm's shoulder or elbow.
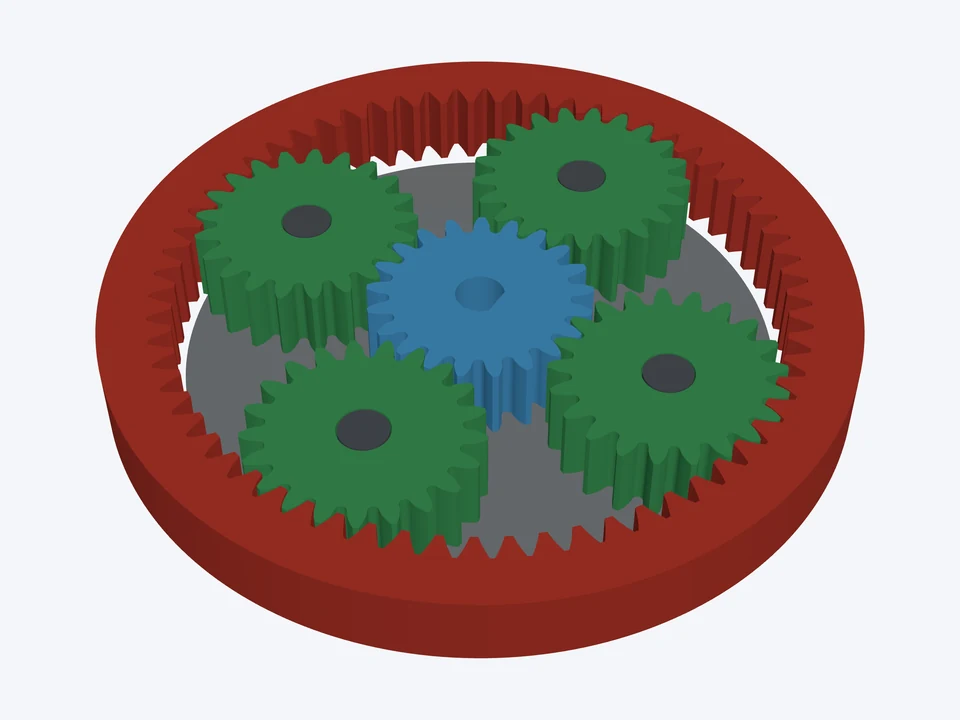

Module 1 · 20° · spur
A short 4 : 1 with a single-sided carrier and four planets, for a robot wrist.
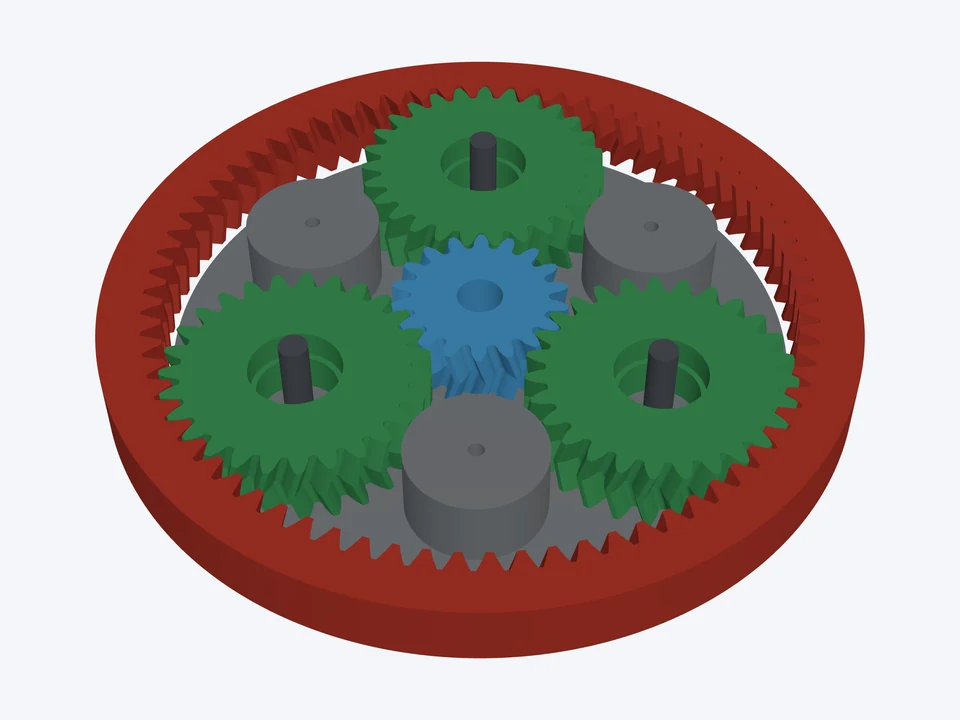

Module 1.5 · 20° · herringbone
Each planet runs on a 625 ball bearing for long life under load.
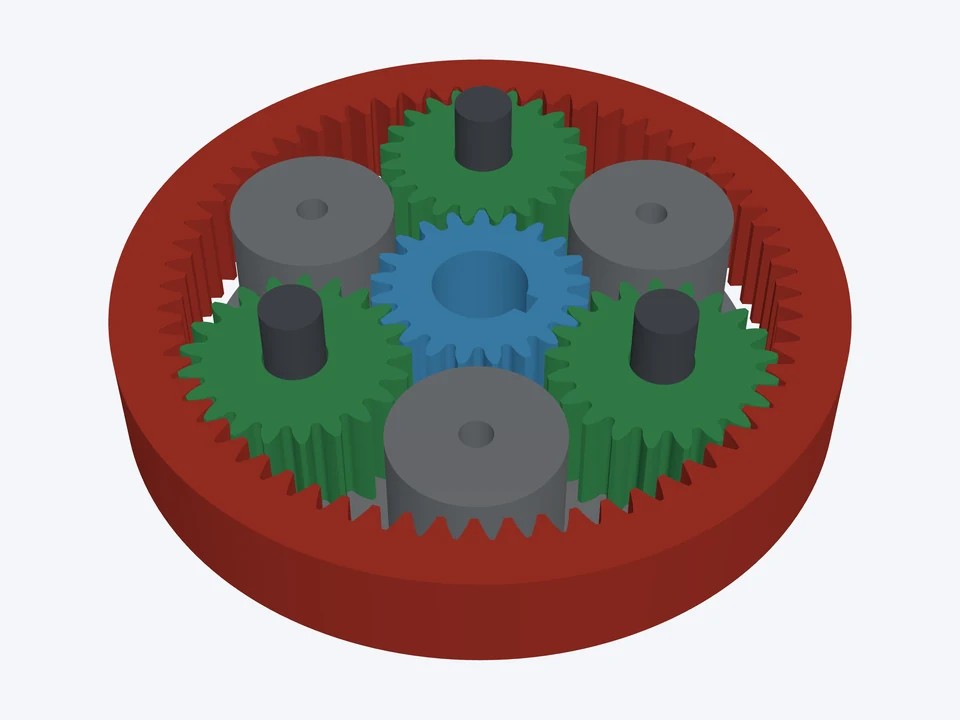

32 DP · 20° · spur
An FRC-style stage: 8 mm keyed motor shaft in, ½" hex out.
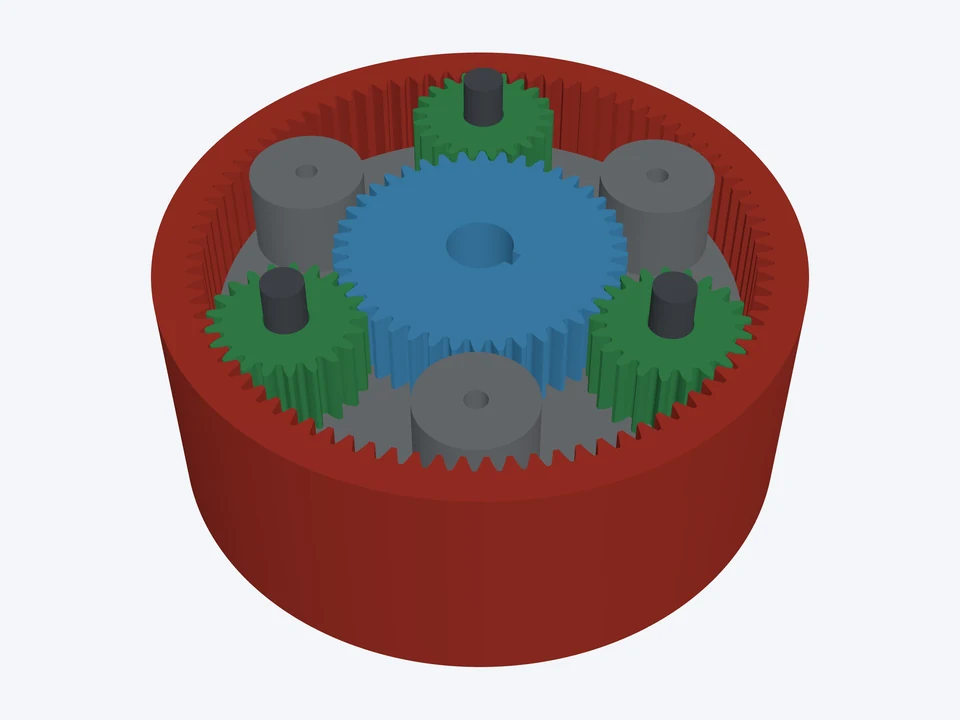

32 DP · 20° · spur
Two 3 : 1 stages, 32 DP, ending in a ½" hex output.
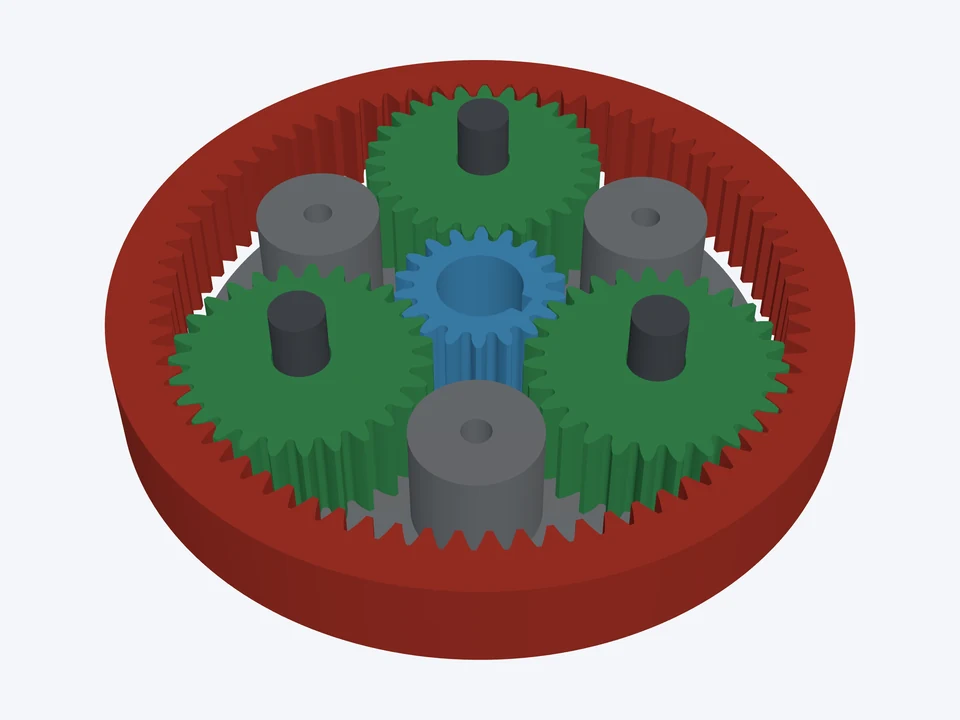

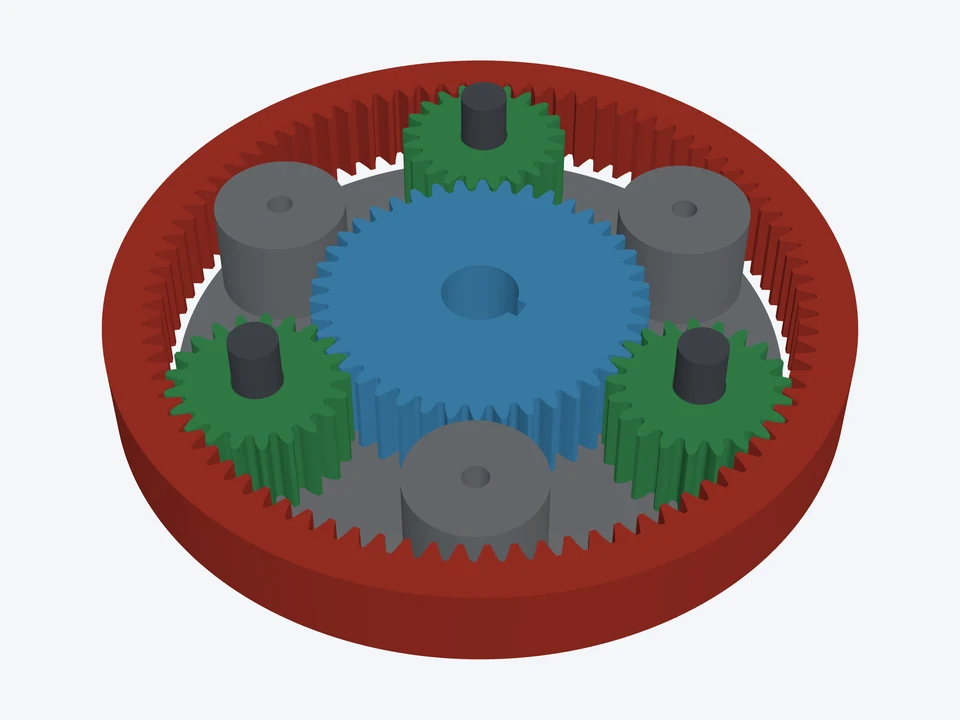

32 DP · 20° · spur
The 3 : 1 stage, a big sun and small planets, 8 mm keyed in, ½" hex out.
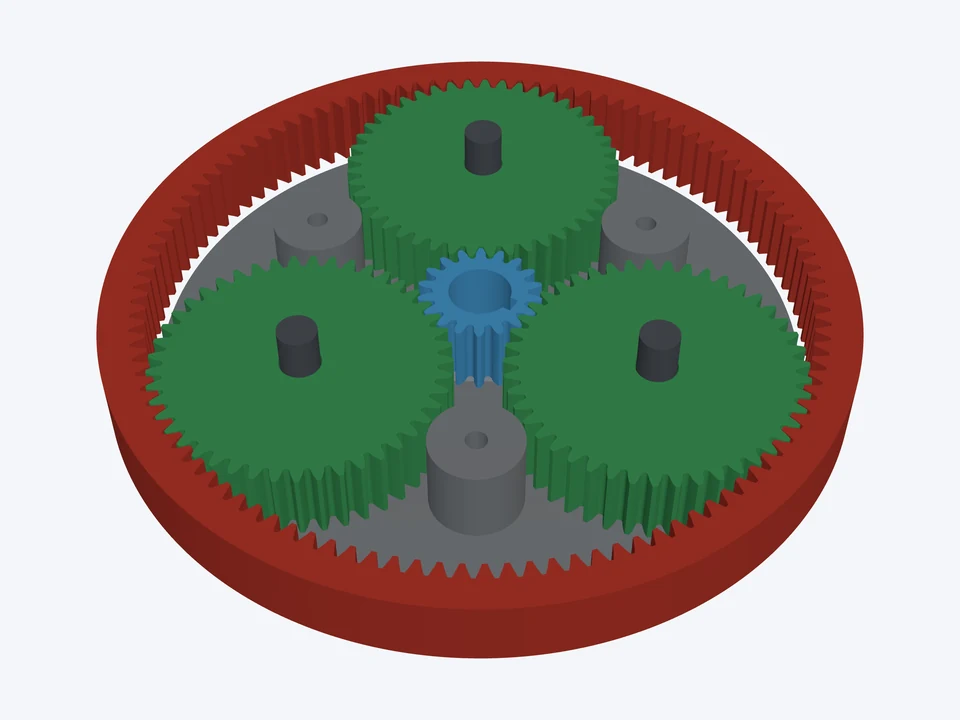

32 DP · 20° · spur
7 : 1 in one stage: an 18-tooth sun, the smallest that takes the 8 mm keyed shaft, ½" hex out.
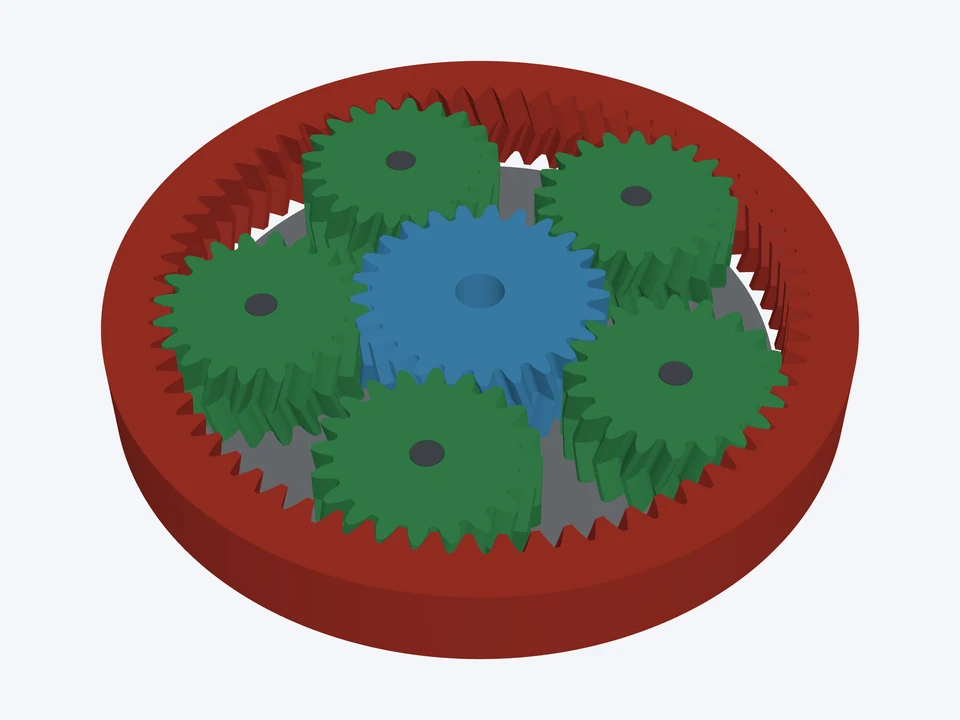

Module 1.5 · 20° · herringbone
The classic printed gear bearing: herringbone teeth hold it together round five planets.
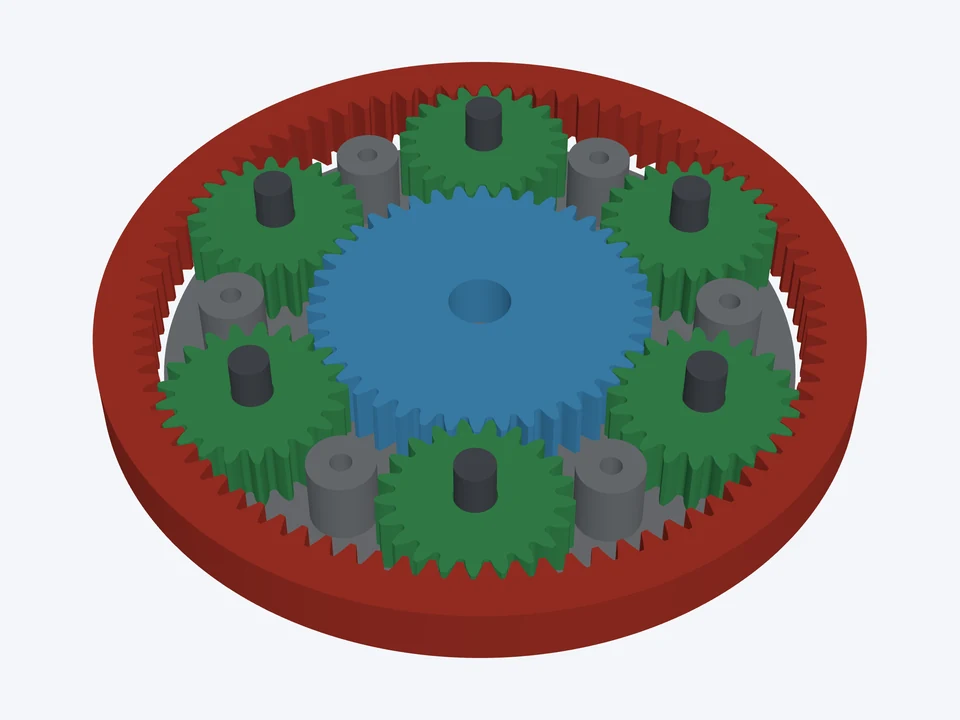

Module 1 · 20° · spur
Six planets round a big sun: a striking demo and a strong, low ratio.
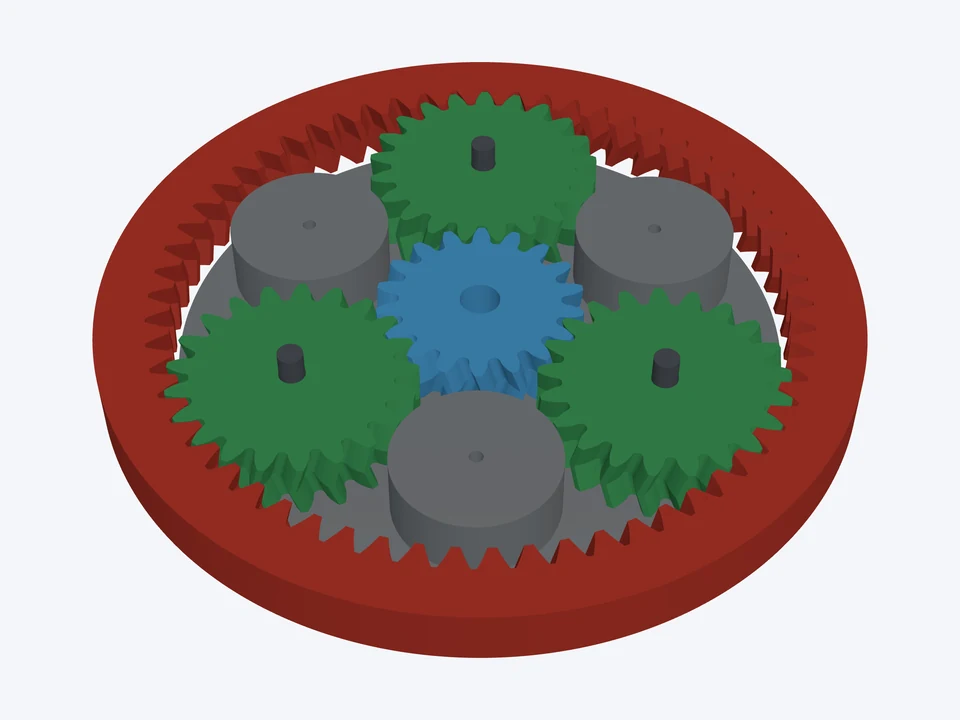

Module 2 · 20° · herringbone
Carrier held, sun in, ring out: the output reverses, as in a turbofan's gearbox.
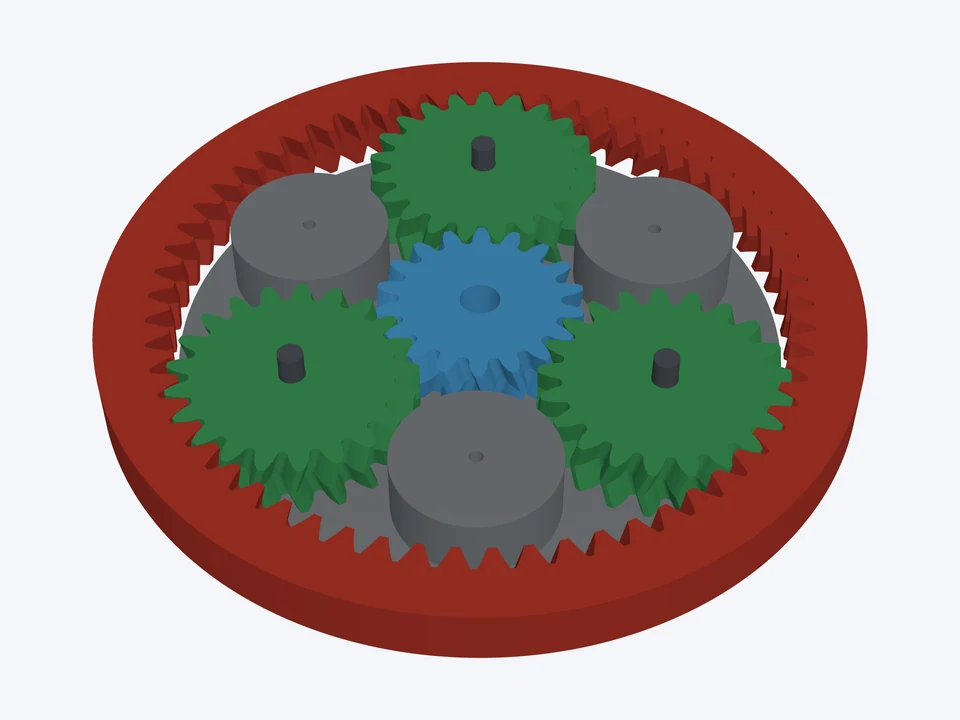

Module 2 · 20° · herringbone
Sun held, carrier in, ring out: the ring overruns the input, like a car's overdrive.
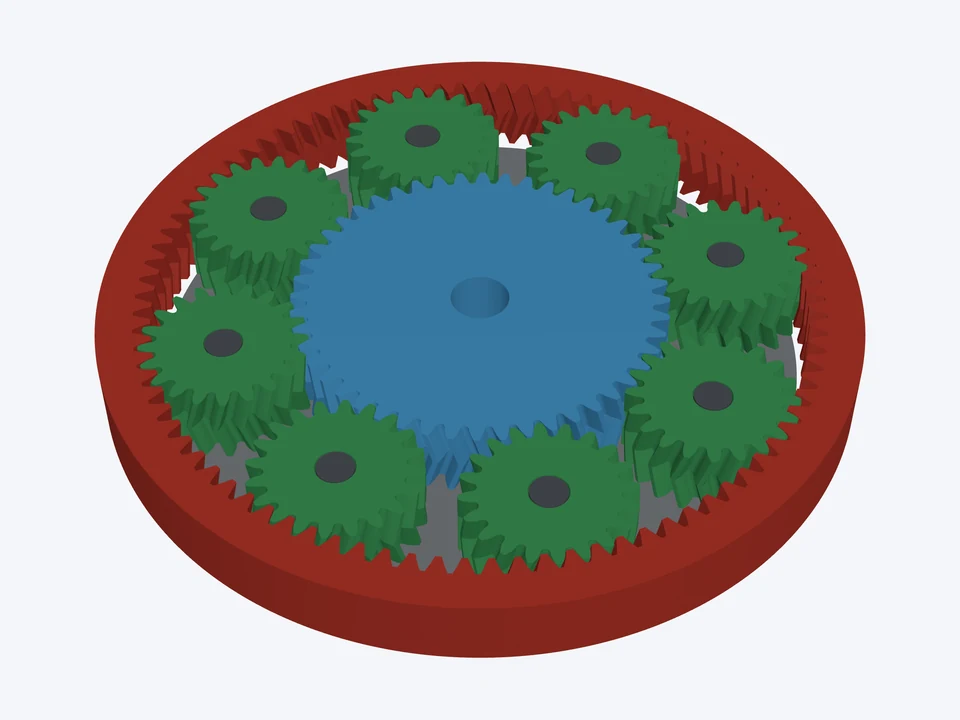

Module 1 · 20° · herringbone
Eight planets fill the ring, the most the app takes, still clear of each other.
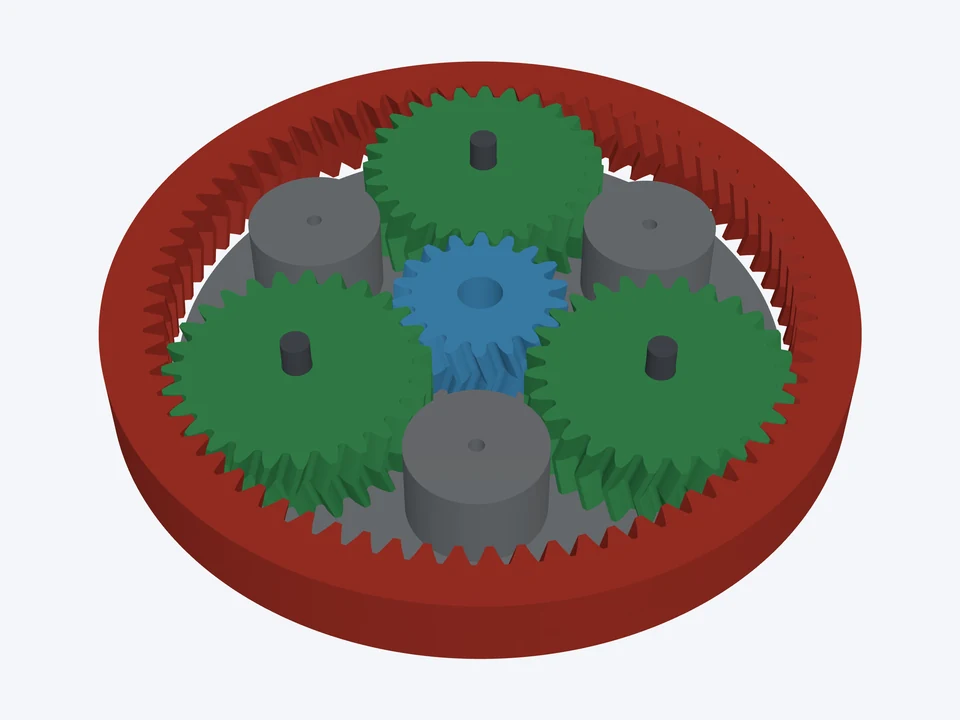

Module 1.5 · 20° · herringbone
Ring held, carrier in, sun out: the sun turns five times as fast, to spin a small generator.
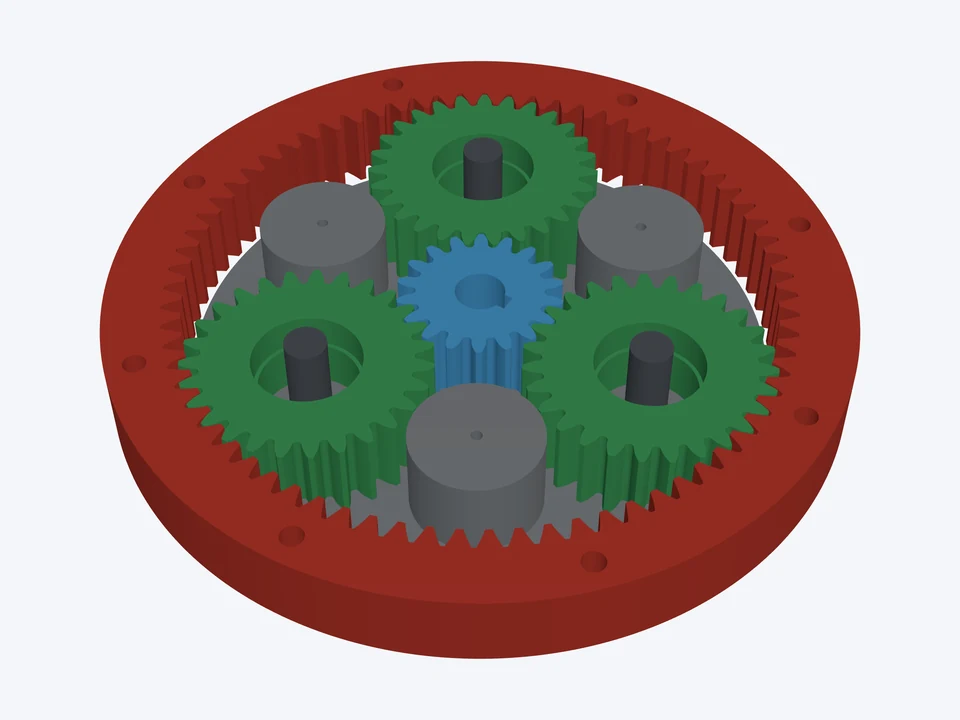

Module 2 · 20° · spur
A metal-ready 5 : 1: keyed shafts, planets on 6000 bearings, a flanged ring with eight M5 bolts.
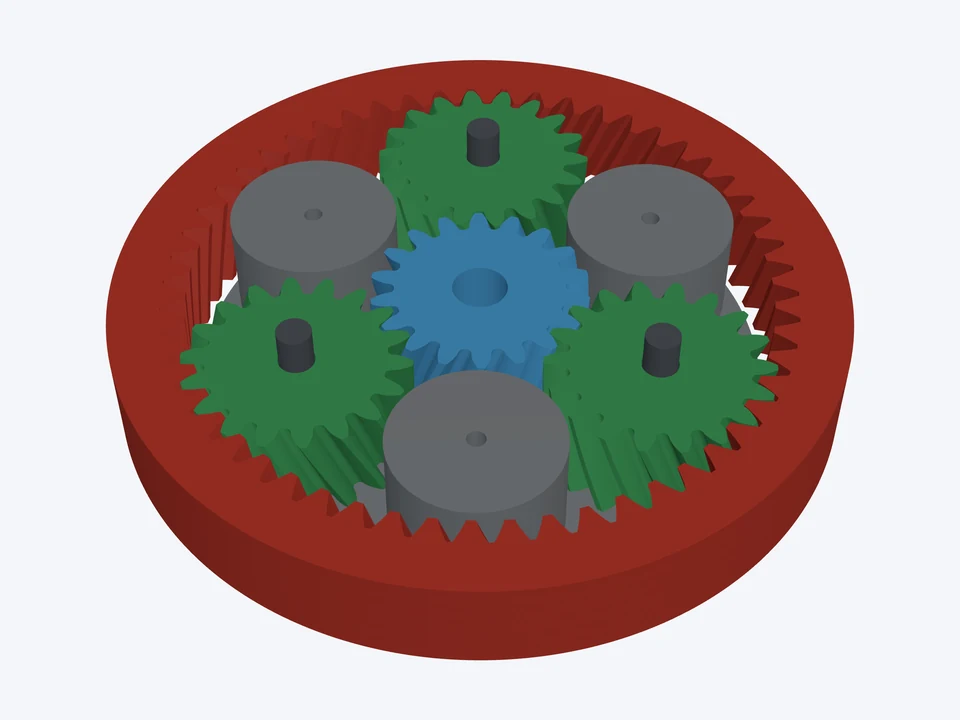

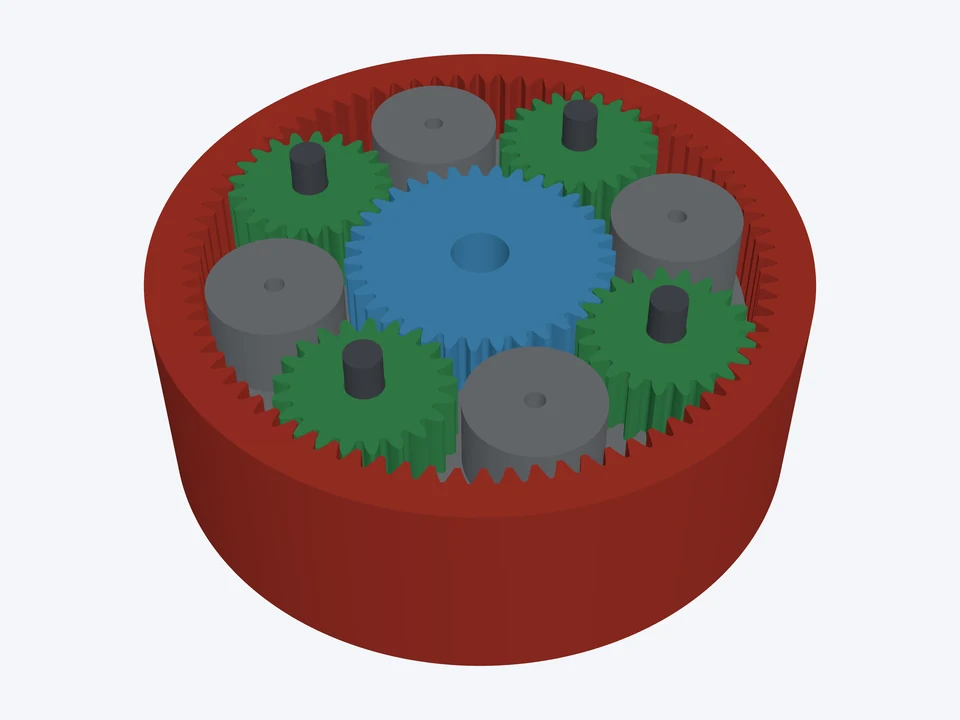

Module 1 · 20° · spur
Two 3.2 : 1 stages with four planets each: about 10 : 1 in a short housing.
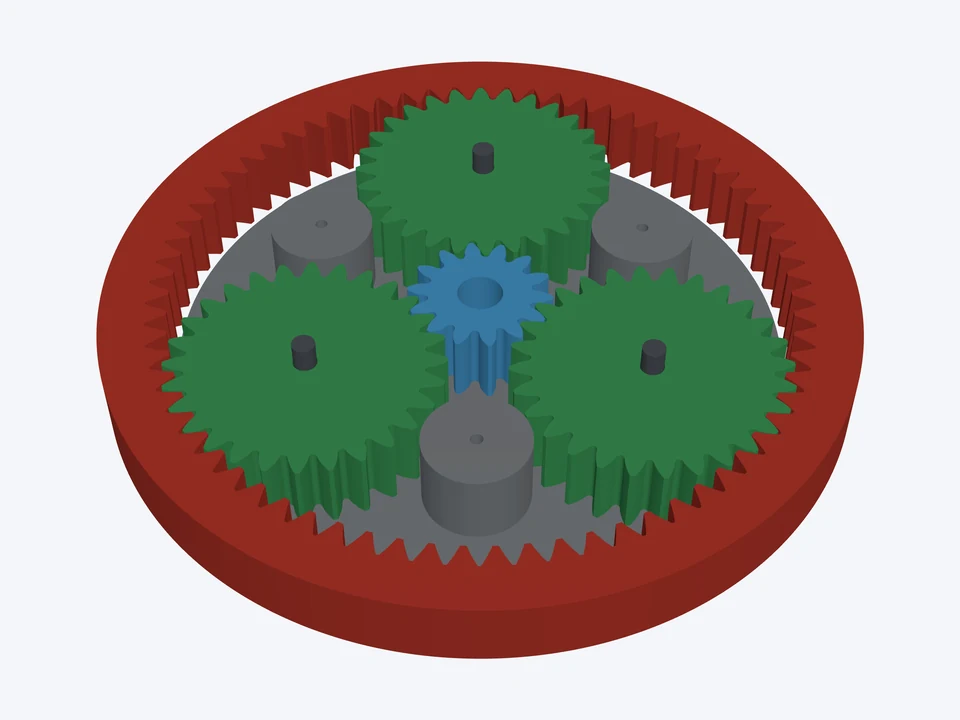

Module 2 · 25° · spur
25° teeth: a 14-tooth sun without undercut and stronger roots, 6 : 1.
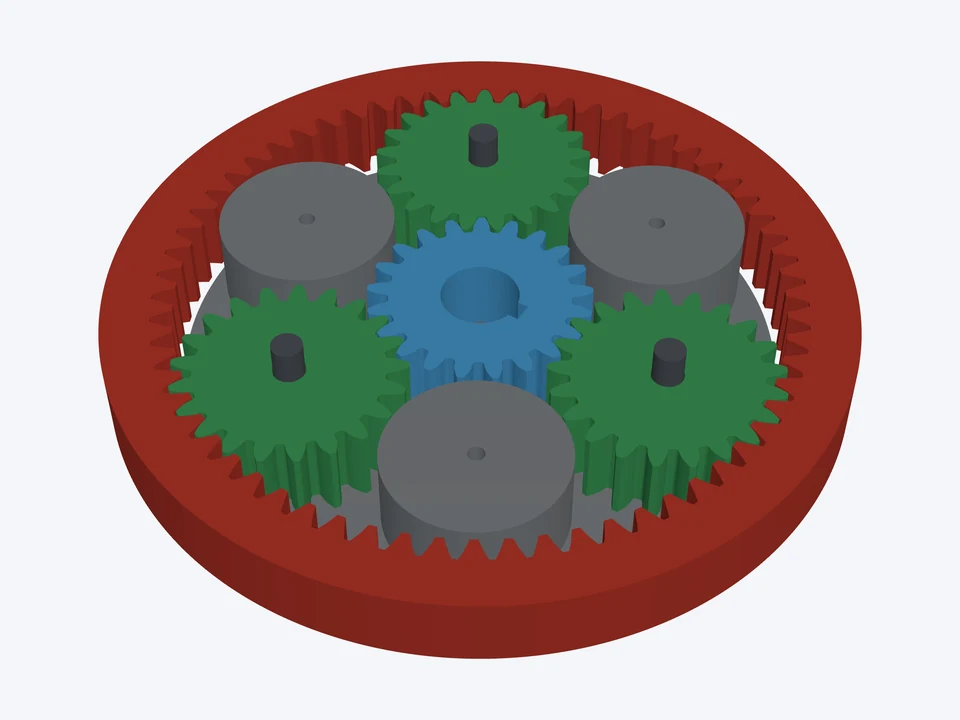

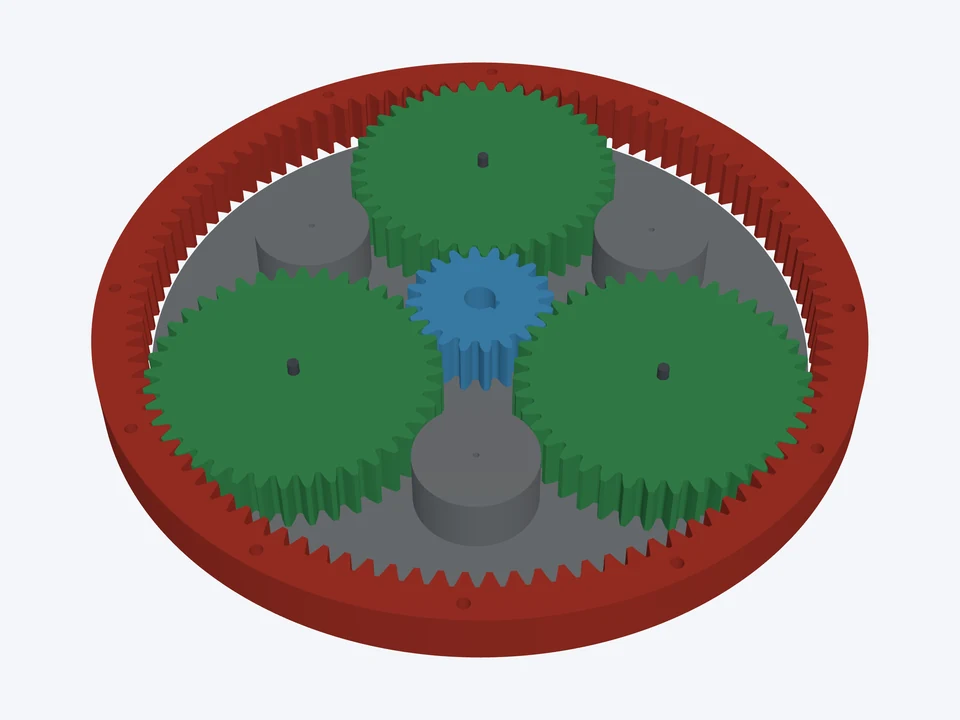

Module 3 · 20° · spur
A big 6 : 1 for a winch or drum: module 3, a 300 mm ring with twelve M5 bolts.
Designing is free; the STL, STEP and the carrier's DXF and SVG download from the app for tokens. Each set was checked in the Planetary Gear Designer and opens with no warnings.