
18 : 60
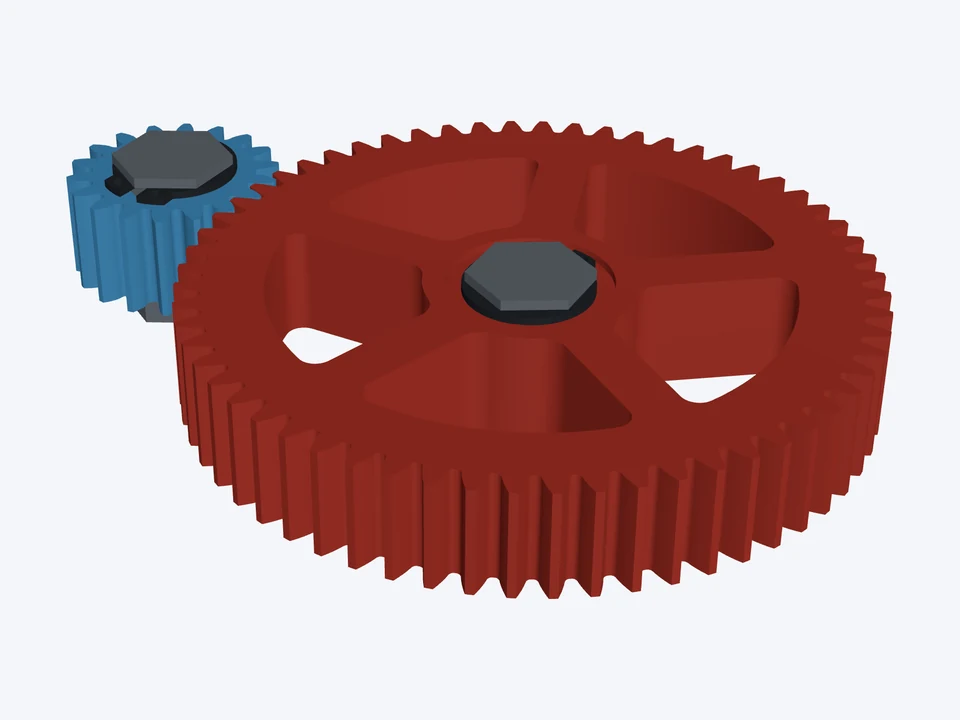

18T : 60T · 20 DP on ½" hex
20 DP · 20°
A 3.33 : 1 robot gearbox stage: 20 DP gears on ½" hex shafts, held by retaining rings.
Spur, helical and herringbone gears, generated the way a cutter makes them. Design one gear or a meshing pair, an internal ring or a rack, and download STL, STEP, DXF or SVG.
ISO 54 modules and the common diametral pitches; 20° standard, plus 14½°, 25° and stub forms.
Involute flanks and the true trochoidal root from rolling the rack — undercut shown as cut.
Any helix angle and hand; the pair takes the opposite hand automatically.
A meshing pair at the right centre distance, an internal ring gear, or a rack.
Shift each gear, with the undercut and pointed-tooth limits from DIN 3960 shown.
Span width over k teeth and dimension over pins — what you measure on the real part.
DIN 3967 tooth thinning series, or your own allowance.
Hubs with set screws or hub pins; D-flat, keyway, ISO 14 and ISO 4156 spline and hex bores with retaining rings, and a sample shaft to match; spokes.
STEP, STL, DXF, SVG and PNG, with print compensation in the STL only; one STEP holds the whole drive.
| System | Sizes | Forms |
|---|---|---|
| Module | ISO 54 modules | 20°, 14½°, 25°, 20° stub; ISO 53 racks A to D |
| Diametral pitch | The common pitches | 20°, 14½°, 25°, 20° stub, Fellows stub |
Robot gearboxes, printed drives, industrial and inch gears, ring gears and racks. Each opens with both parts in mesh, ready to change.
20 DP · 20°
A 3.33 : 1 robot gearbox stage: 20 DP gears on ½" hex shafts, held by retaining rings.
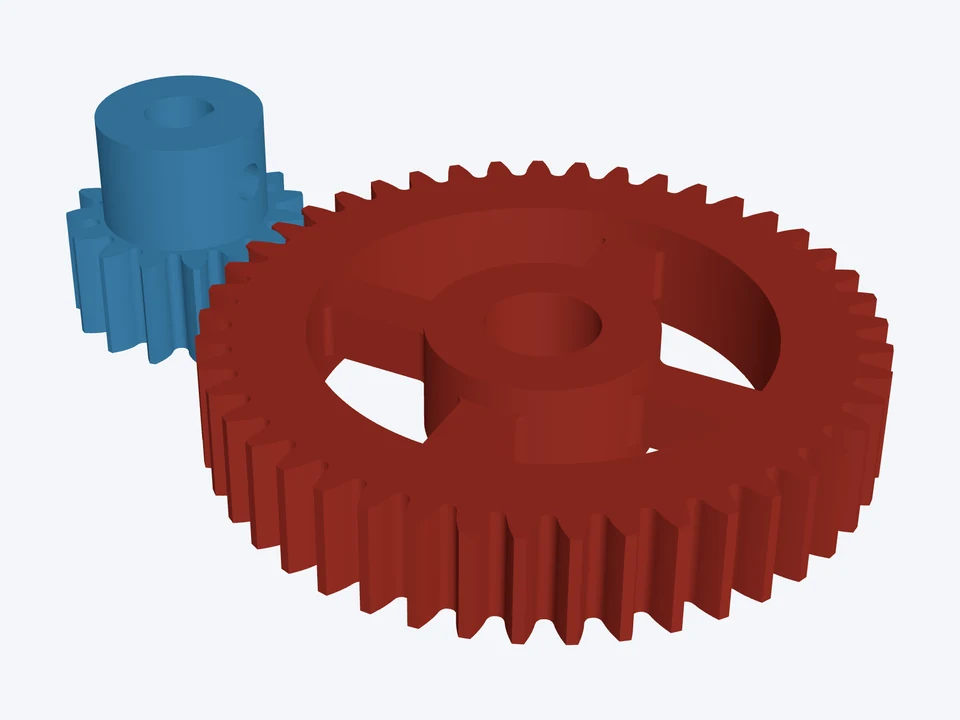

module 1 · 20°
A 3 : 1 printed reduction for a NEMA 17 stepper: the pinion on its 5 mm D-flat shaft.
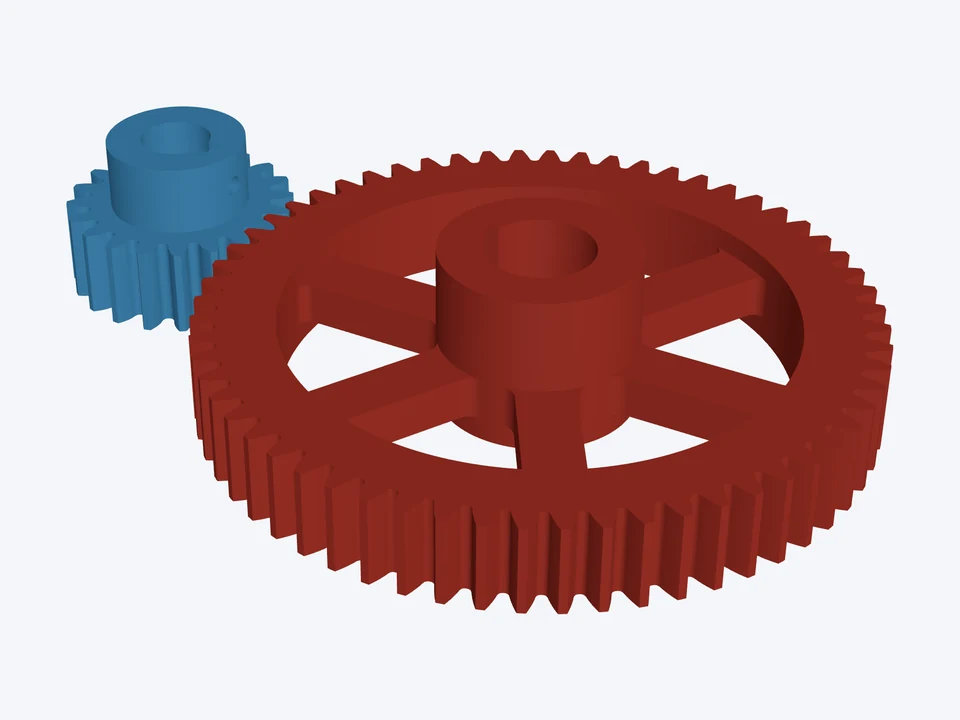

module 3 · 20°
A 3 : 1 module 3 spur pair on DIN 6885 keyed shafts, a hub on each gear.
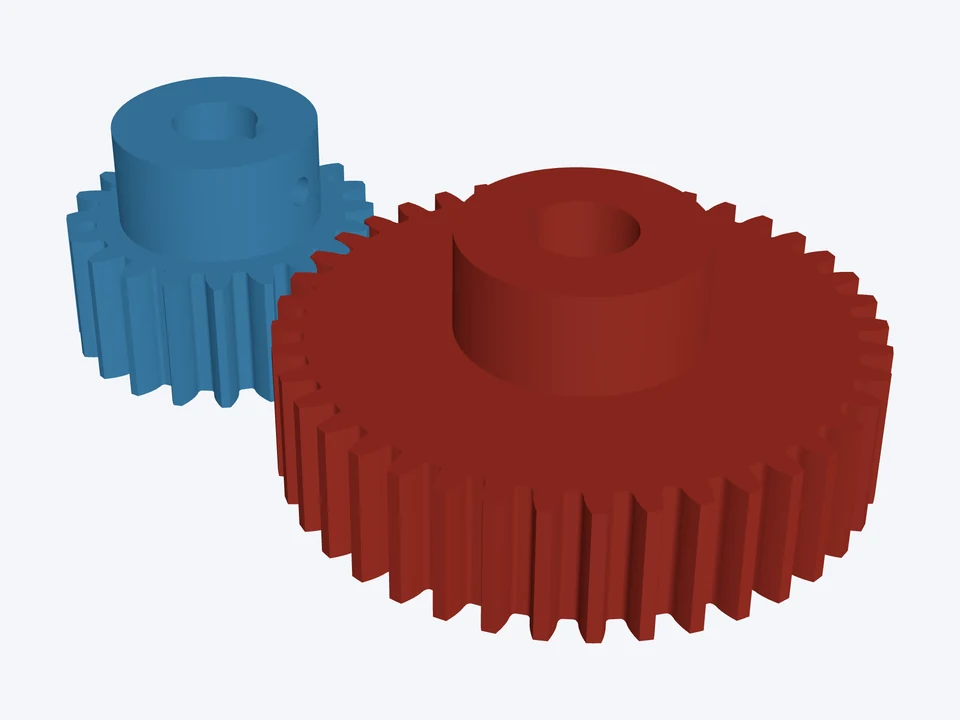

10 DP · 14½°
The classic catalogue pair: 10 DP, 14½° pressure angle, keyed inch bores and hubs.
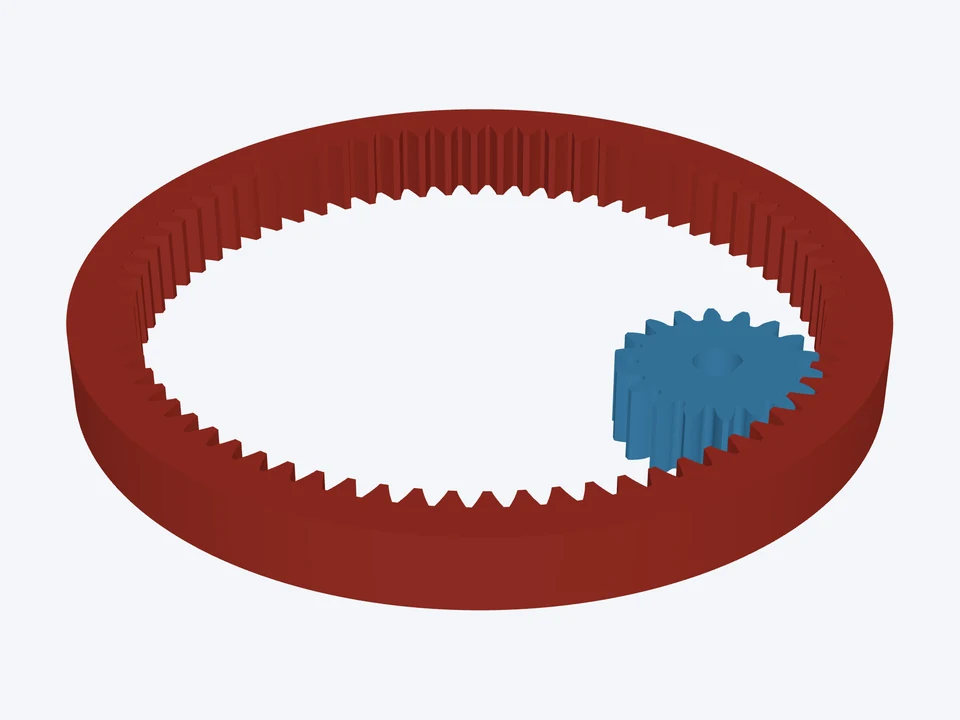

module 1 · 20°
An internal (ring) gear and its pinion: compact, both turning the same way.
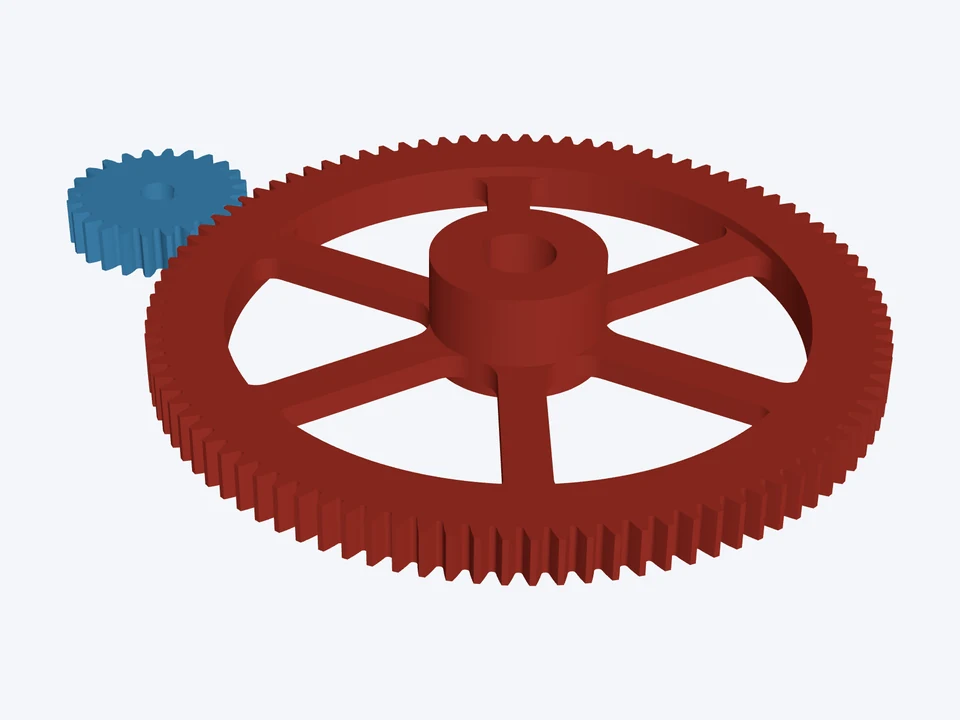

module 3 · 20°
A big six-spoke module 3 gear: a wide rim, a thinned web and a keyed hub with a set screw.
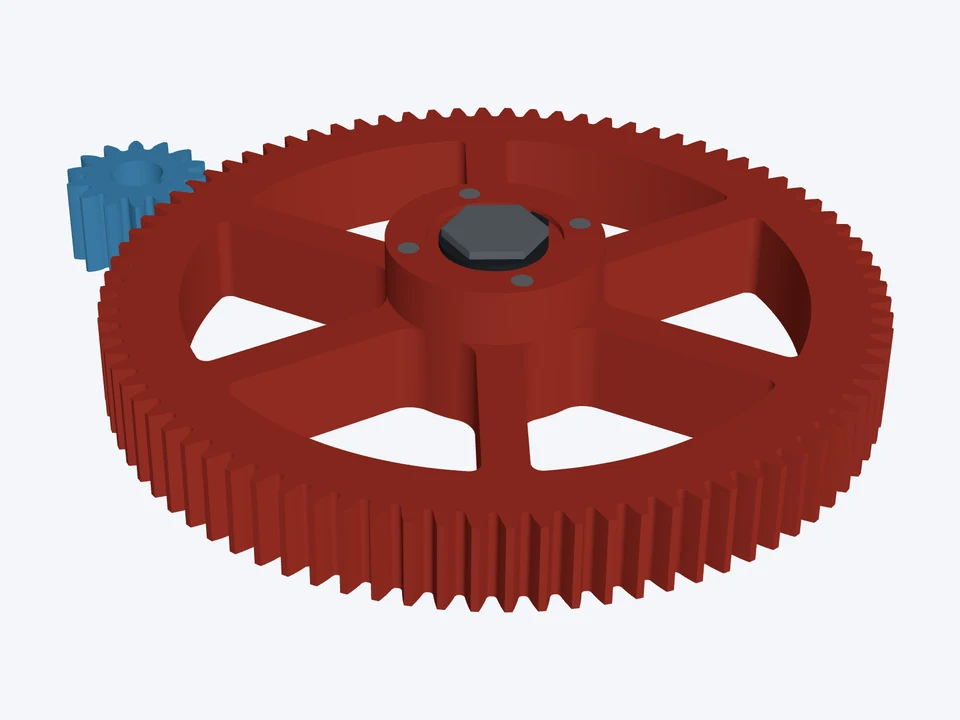

20 DP · 20°
A 6 : 1 arm reduction: a pinion on an 8 mm keyed motor shaft into an 84-tooth, six-spoke gear on ½" hex.
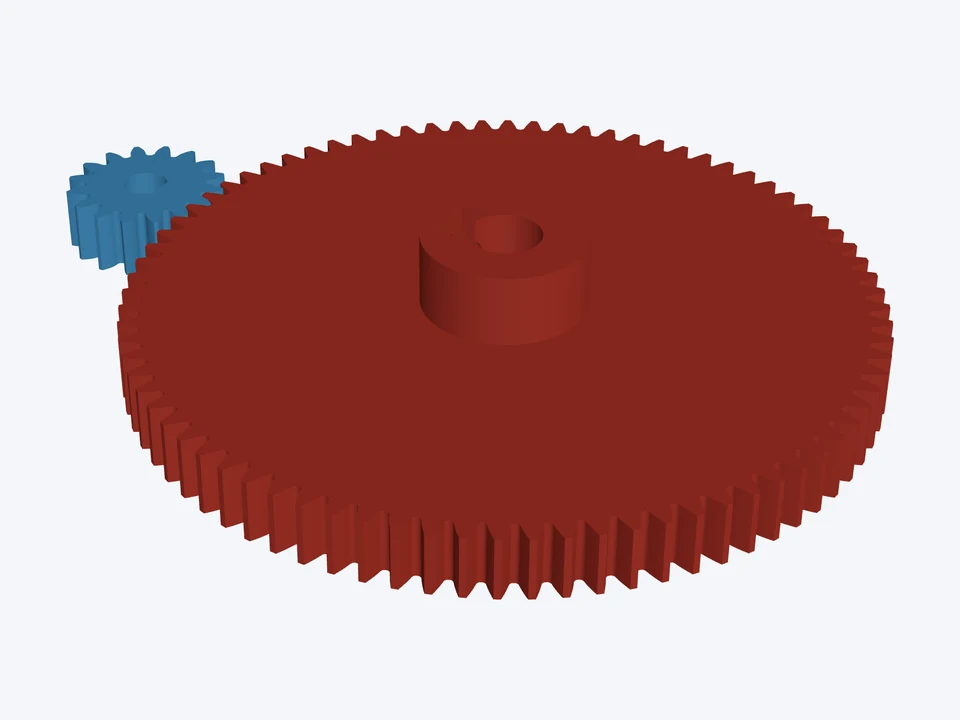

module 1 · 20°
An extruder's 5 : 1 reduction: a 16-tooth pinion, profile-shifted so it isn't undercut.
STEP (true nominal size, for CAD), STL (with your print compensation, for 3D printing), DXF and SVG (true lines and arcs, for laser cutting and CAD sketches) and PNG, for each gear; for a pair, the STEP holds both gears in mesh.
Turn on the two-gear drive: gear 2 takes the same module or pitch and the opposite helix hand, and the centre distance follows from the two profile shifts. The check warns about undercut, pointed teeth and contact ratio, and Auto-fix clears what it can.
Each gear's Dimensions show the span width over k teeth and the dimension over pins, with their limits for the backlash allowance you chose: measure the part and compare.
Yes. Designing and checking are free; downloads cost a few tokens, the same as for pulleys and sprockets, and one purchase covers every file of that design, and you can download them again at no charge later. See Pricing.