
6 : 1
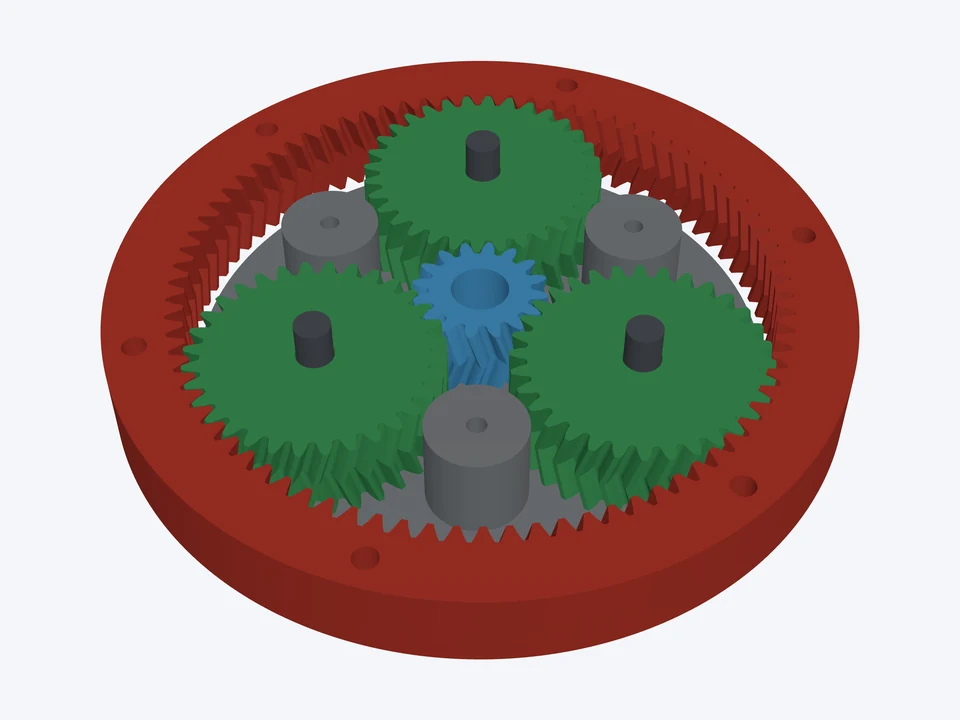

6 : 1 · quasi-direct-drive actuator
Module 1 · 20° · herringbone
The low-ratio stage legged robots put behind a brushless motor; flanged ring, six M3 bolts.
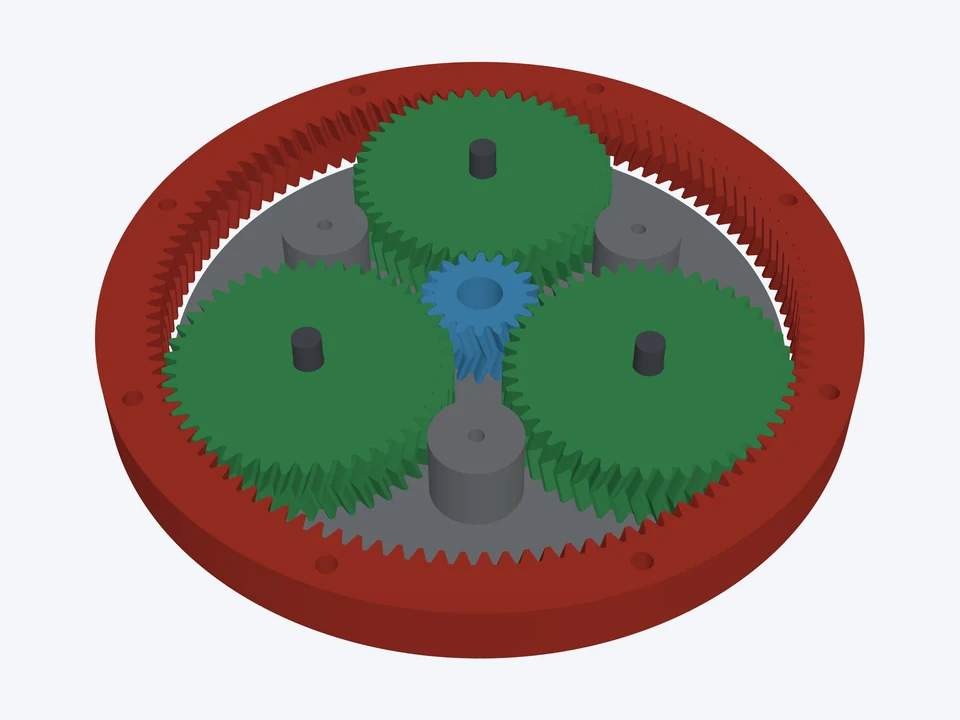
7 : 1 in one stage: a small sun and big planets, still back-drivable.
Using the CheapCADTools connector, design a 7 : 1 planetary gear set in Planetary Gear Designer: module 1 mm, 20° pressure angle, herringbone teeth, an 18-tooth sun, 45-tooth planets and a 108-tooth ring, three planets, face width 12 mm. The sun: an 8 mm bore. The carrier's output: a 10 mm bore. The ring: eight M3 bolt holes, an 8.5 mm rim below the roots. Check the design, apply any Auto-fix it suggests, then export every part (the sun, a planet, the ring and the carrier) as STEP and STL and give me the download link.
Paste it into Claude, ChatGPT or any AI app with the CheapCADTools connector, and it designs this planetary set with you, checks it and hands you the files. How to connect your AI.
The link opens the whole set in the Planetary Gear Designer's 3D view. Change the teeth, the number of planets or stages, which member is held, the carrier, bores or hubs, then download STL, STEP or the carrier's DXF and SVG.
Module 1 · 20° · herringbone
The low-ratio stage legged robots put behind a brushless motor; flanged ring, six M3 bolts.
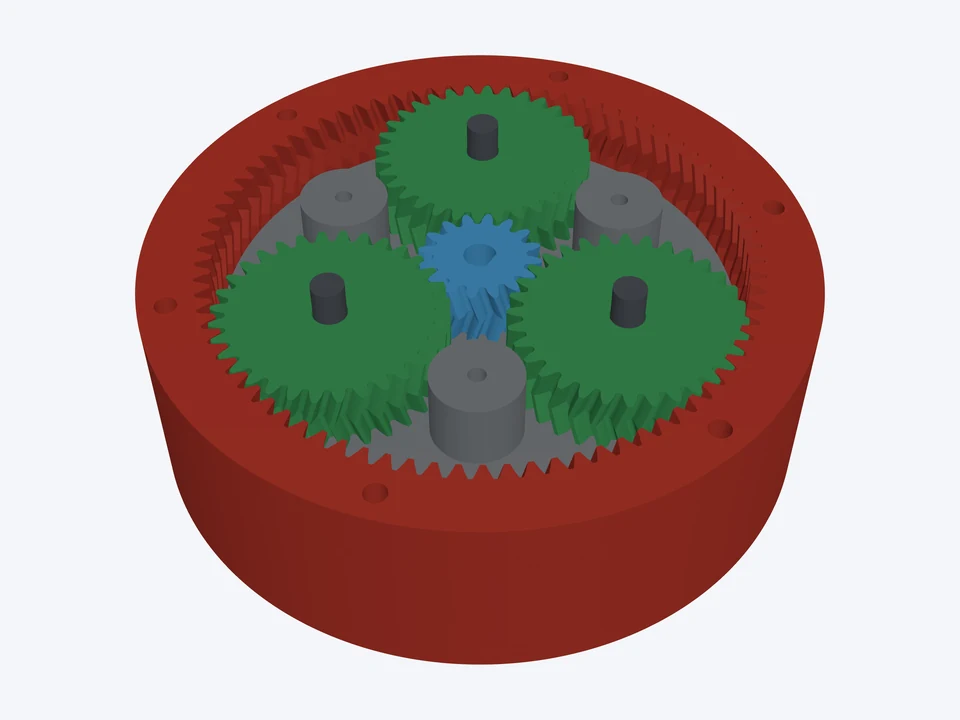

Module 1 · 20° · herringbone
Two 6 : 1 stages for a printed robot arm's shoulder or elbow.
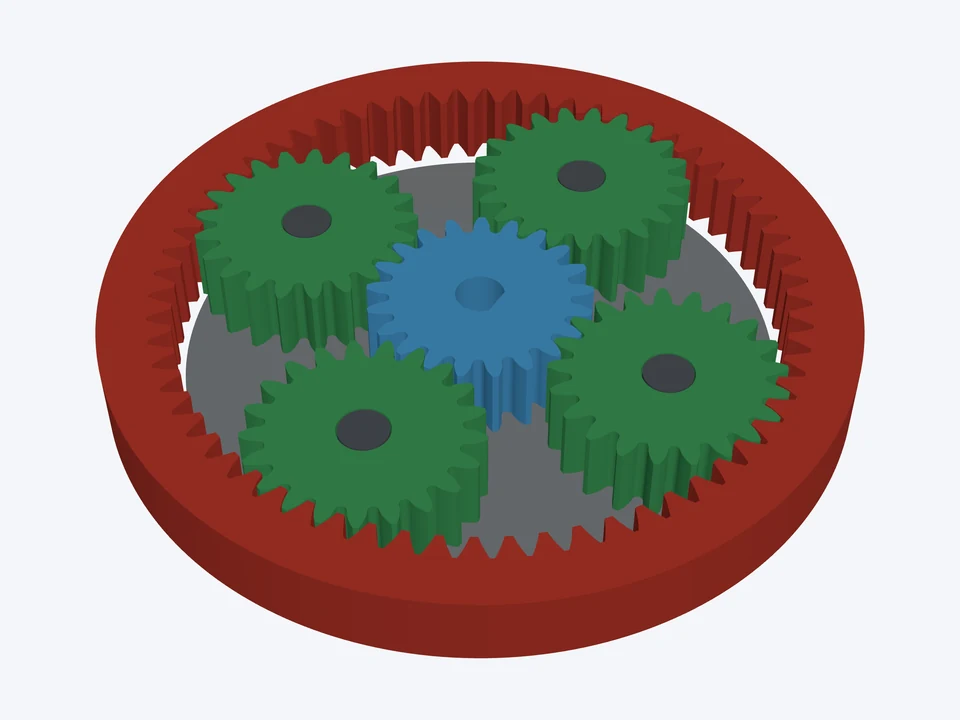

Module 1 · 20° · spur
A short 4 : 1 with a single-sided carrier and four planets, for a robot wrist.
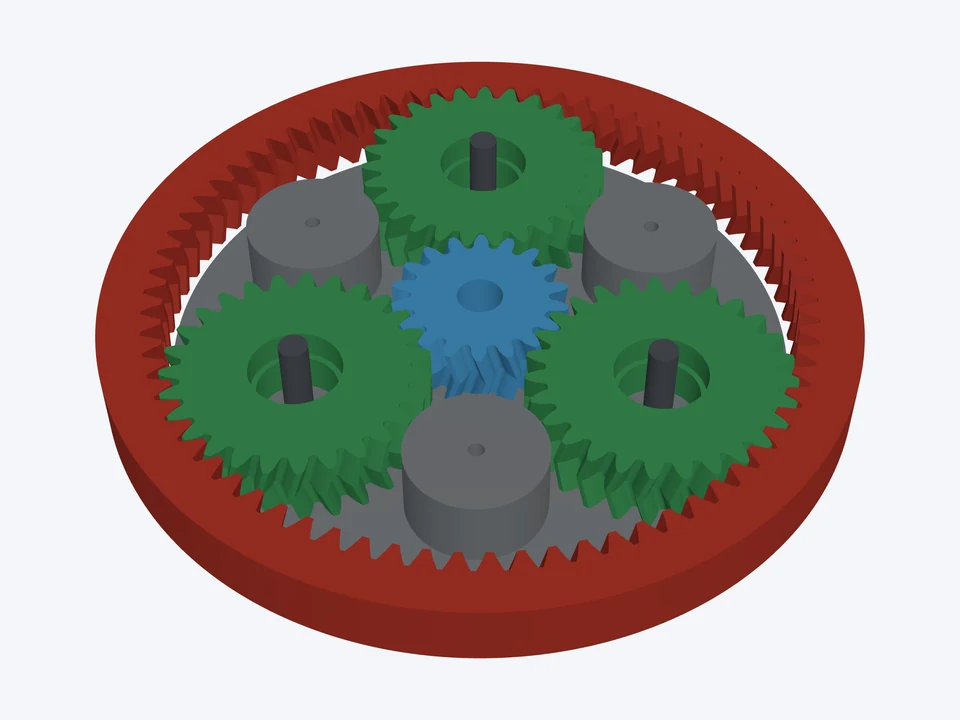

Module 1.5 · 20° · herringbone
Each planet runs on a 625 ball bearing for long life under load.