
15 : 45
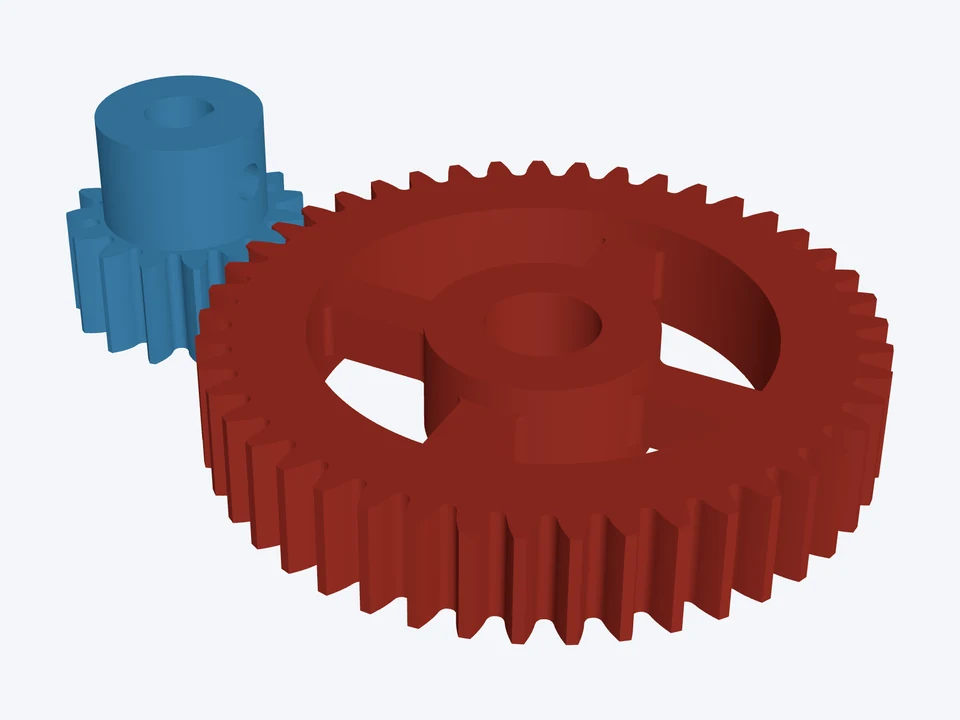

15T : 45T · NEMA 17 reducer
module 1 · 20°
A 3 : 1 printed reduction for a NEMA 17 stepper: the pinion on its 5 mm D-flat shaft.
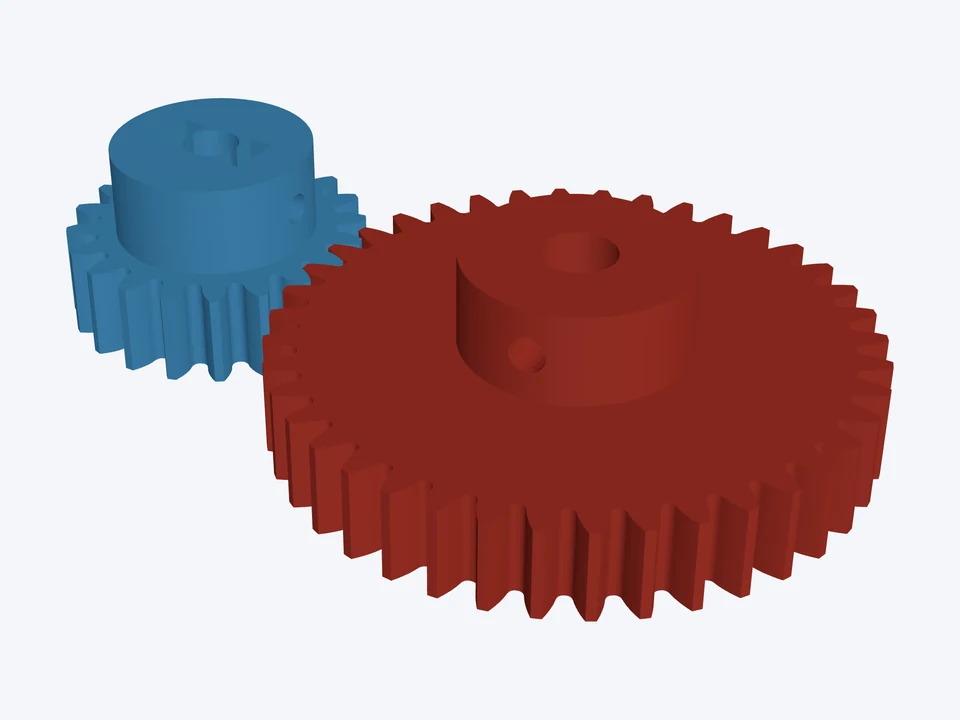
Two ways to hold a printed gear: captured nuts on the pinion, heat-set inserts on the gear.
Using the CheapCAD Tools connector, design a two-gear drive in Gear Designer: module 1.5 mm, face width 10 mm. Gear 1: 20 teeth, a 6 mm bore, a hub on one face, Hub OD 22 mm, Hub Height 10 mm, 2 M3 set screws with captured nuts. Gear 2: 40 teeth, an 8 mm bore, a hub on one face, Hub OD 24 mm, Hub Height 10 mm, 2 M3 set screws in heat-set inserts (insert hole 4 mm). Check the design, apply any Auto-fix it suggests, then export both gears as STL and give me the download link.
Paste it into Claude, ChatGPT or any AI app with the CheapCAD Tools connector, and it designs this gear set with you, checks it and hands you the files. How to connect your AI.
The link opens both parts in the Gear Designer's 3D Mode. Change the teeth, module or pitch, bore, hub or spokes, then download STL, STEP, DXF or SVG.
module 1 · 20°
A 3 : 1 printed reduction for a NEMA 17 stepper: the pinion on its 5 mm D-flat shaft.
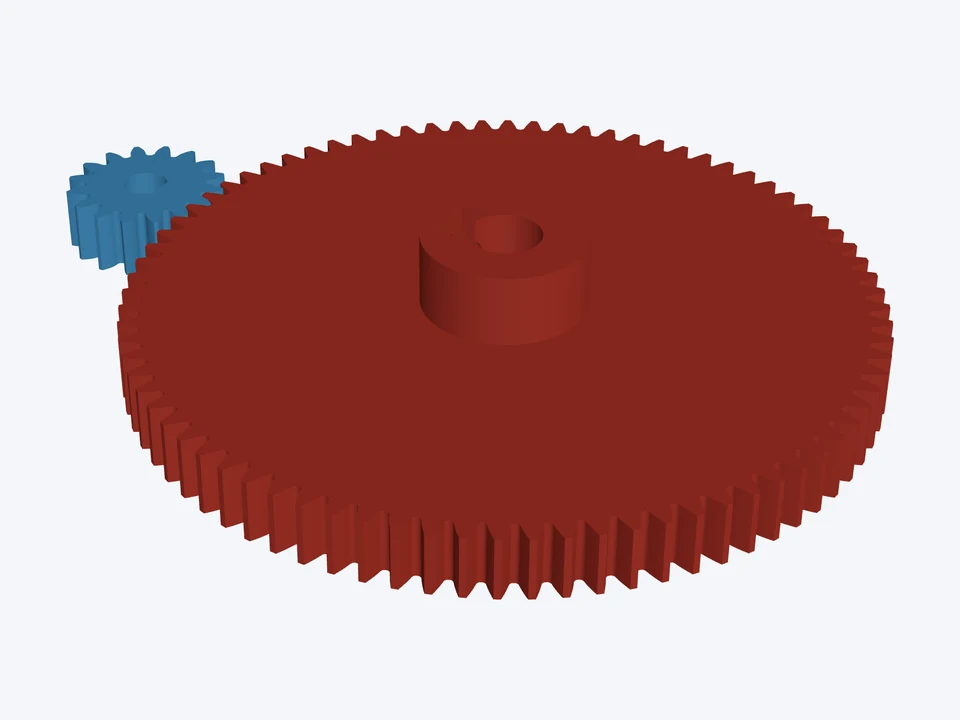

module 1 · 20°
An extruder's 5 : 1 reduction: a 16-tooth pinion, profile-shifted so it isn't undercut.
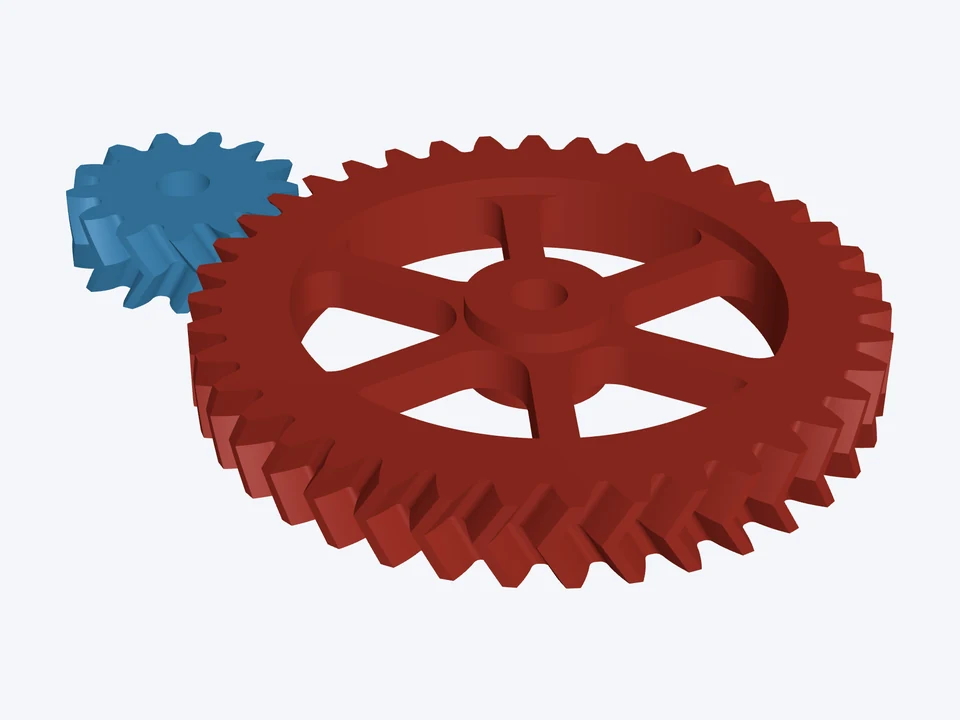

module 2 · 20° · herringbone 30°
The classic printable herringbone pair: self-centring, 3 : 1, spoked.
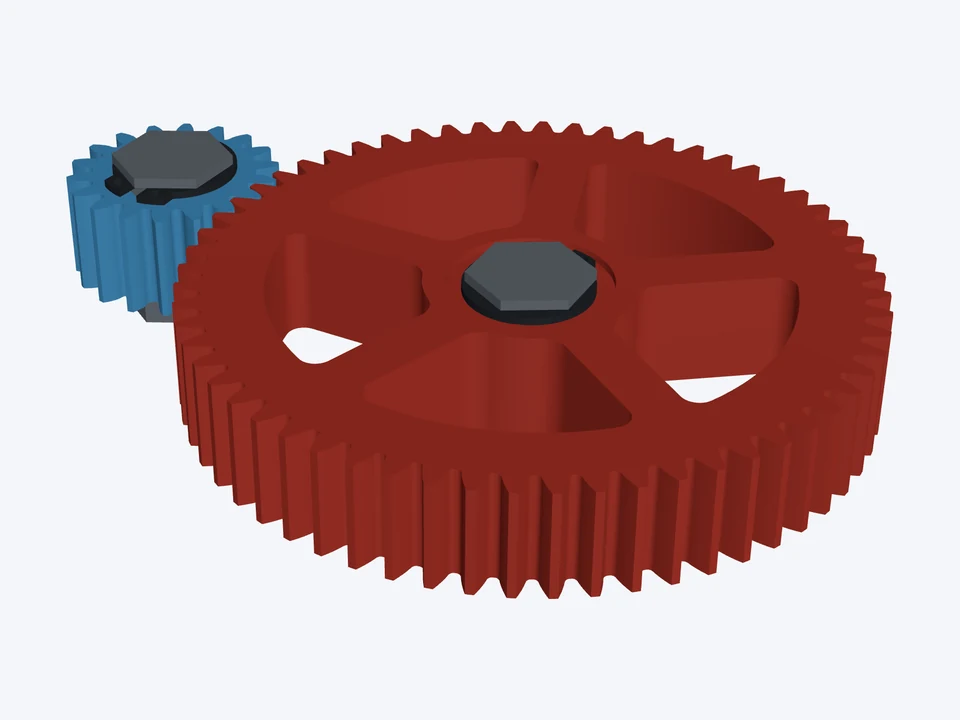

20 DP · 20°
A 3.33 : 1 robot gearbox stage: 20 DP gears on ½" hex shafts, held by retaining rings.